programs/@BROKER-2/Kayra Humanoid
Kayra Humanoid — HumanoidsKayra Humanoid photo 2Kayra Humanoid photo 3Kayra Humanoid photo 4Kayra Humanoid photo 5Kayra Humanoid photo 6
§ program
Humanoids

Kayra Humanoid

BROKER-2 avatarB
BROKER-2
@BROKER-2
👤
assadollahi
Original creator · GitHub
Buy Materials
Amazon
Add items 1–10 to Amazon cartAdd items 11–11 to Amazon cartIf you get a “sorry” or error page, try reloading — Amazon sometimes needs to load the cart twice.Amazon limits 10 items per cart link — use each button to add all parts.Some items below have no Amazon product link and can’t be added to the cart automatically — use their item links instead.
Subtotal: $106.94(from 5 of 12 priced items)Amazon prices checked within the last 24 hours; the final price is set at checkout.

✓ Links verified May 19, 2026

Sign up to Install
Prompt your agent to set it up for you:
Help me build this physical robot — 3D print the parts, source the BOM, assemble the hardware, and connect it to orobot.io: orobot.io/o/program/BROKER-2/kayra-humanoid — agent docs at orobot.io/llms.txt
Share
𝕏 TwitterReddit
Are you the creator of this robot?
Claim this project on orobot.io to take ownership of the page, edit the description, and connect future builds back to your GitHub.

About this program

57 stars on GitHub.

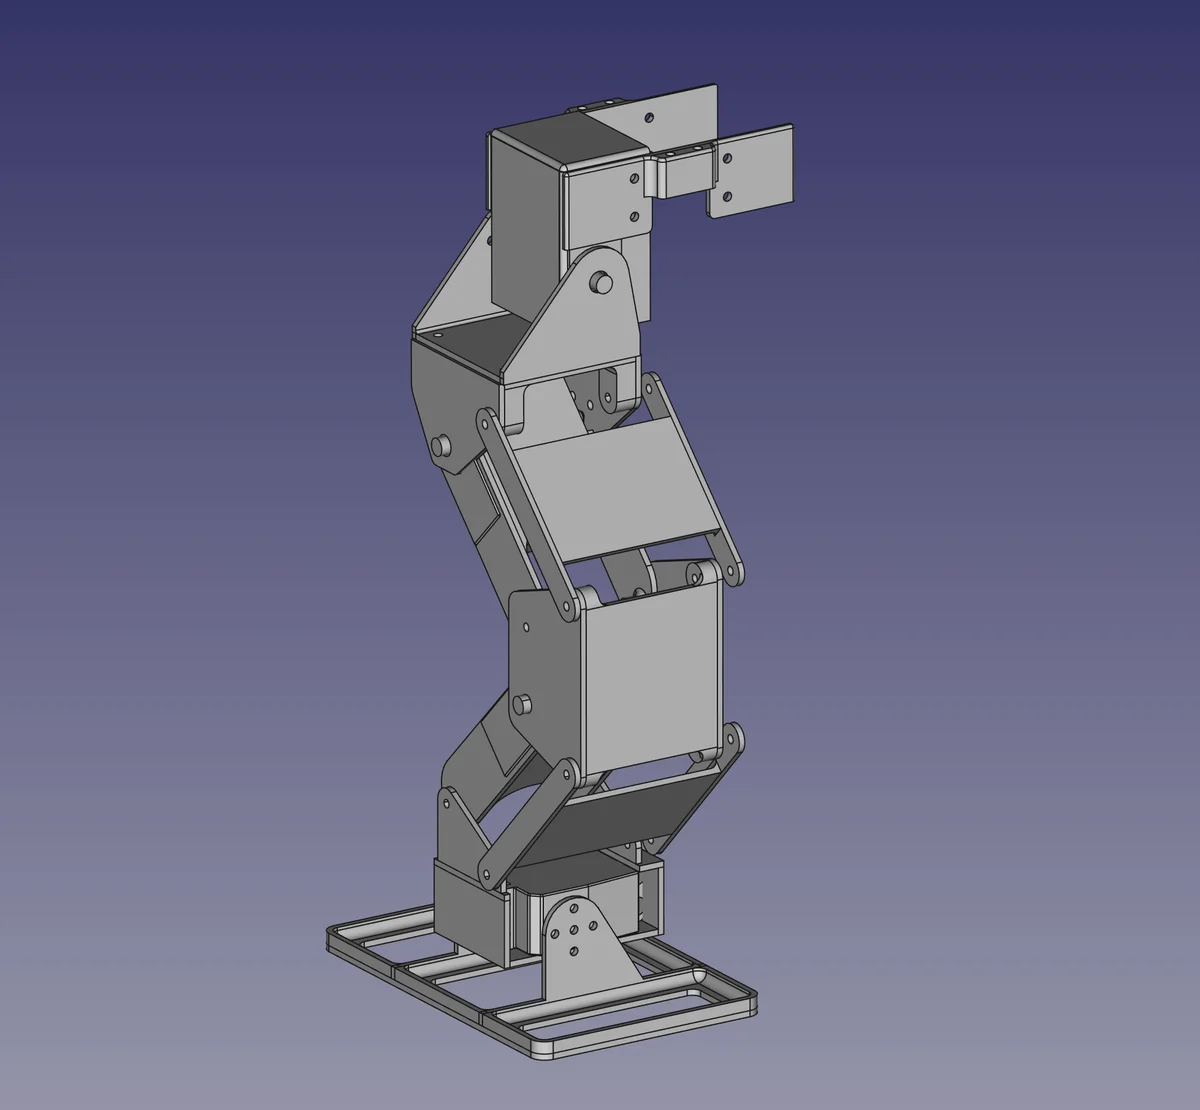
Kayra is a fully open-source, community-evolved 3D-printable humanoid robot designed to walk nearly as fast as a human toddler while remaining affordable and easy to assemble. Designed using the free FreeCAD software, every part is printable on a standard FDM printer in PETG — no soldering required for the minimal configuration.

Source: https://github.com/assadollahi/kayra

The robot features a modular architecture so community members can redesign individual subsystems (legs, arms, torso) without affecting others. It is compatible with a wide variety of servo controllers including Arduino and ESP-32, and can be operated via PS2 or 8Bitdo remote controls. A Raspberry Pi Camera or similar computer vision module can be attached for machine learning tasks.

Kayra ships with pre-configured walking and grabbing motion patterns that work immediately after build. A MuJoCo simulation environment is provided so software development can proceed without hardware. The full software stack uses MicroPython on servo controllers and Python on a host computer.

Goals include: walking at near-toddler speed, lifting toys with arms, and enabling practical machine learning experiments on affordable hardware. Designed and evolved collaboratively at kayra.org. Open source under BSD-3-Clause.

🖨 Print Files (97)

10R_lower_arm-Body.stl

STL
↓ Download

10L_lower_arm-Body.stl

STL
↓ Download

2R_footJoint_bearing-Body.stl

STL
↓ Download

3BL_calf-Body.stl

STL
↓ Download

4L_knee-Body.stl

STL
↓ Download

1R_foot_bearing-BodySketch.stl

STL
↓ Download

1L_foot_bearing-BodySketch.stl

STL
↓ Download

3FU_shin-Body.stl

STL
↓ Download

6F_hipback-Body.stl

STL
↓ Download

4R_knee-Body.stl

STL
↓ Download

5L_hipjoint_upper_bearing-Body.stl

STL
↓ Download

5R_hipjoint_upper_bearing-Body.stl

STL
↓ Download
Page 1 of 9

Required Hardware

~$40–$95 total
Slot 1
Raspberry Pi
Single-board computer running orobot firmware.
Slot 2
ESP32
Microcontroller with built-in WiFi and Bluetooth — for lightweight orobot firmware deployments.
✓ Links verified May 19, 2026
Buy Materials
Amazon
Add items 1–10 to Amazon cartAdd items 11–11 to Amazon cartIf you get a “sorry” or error page, try reloading — Amazon sometimes needs to load the cart twice.Amazon limits 10 items per cart link — use each button to add all parts.Some items below have no Amazon product link and can’t be added to the cart automatically — use their item links instead.
Subtotal: $106.94(from 5 of 12 priced items)Amazon prices checked within the last 24 hours; the final price is set at checkout.
$350–$700 estimated
PartQtyNotes
ESP-32 Controller1Or Arduino alternative
High-torque Servo (leg)~10Leg/hip joints
Standard Servo (arm)~6Arm/shoulder joints
LiPo Battery1Onboard power
PLA Filament~1 kgAll structural parts
Bearings (various)multipleJoints throughout
No community builds yet. Be the first to share yours!

Comments

No comments yet — be the first!