


ArachnoBot Hexapod
 B
✓ Links verified Aug 31, 2026
Guides and BOM only — orobot firmware does not yet support this hardware.
Sign up to ExploreAbout this program
68 stars on GitHub.
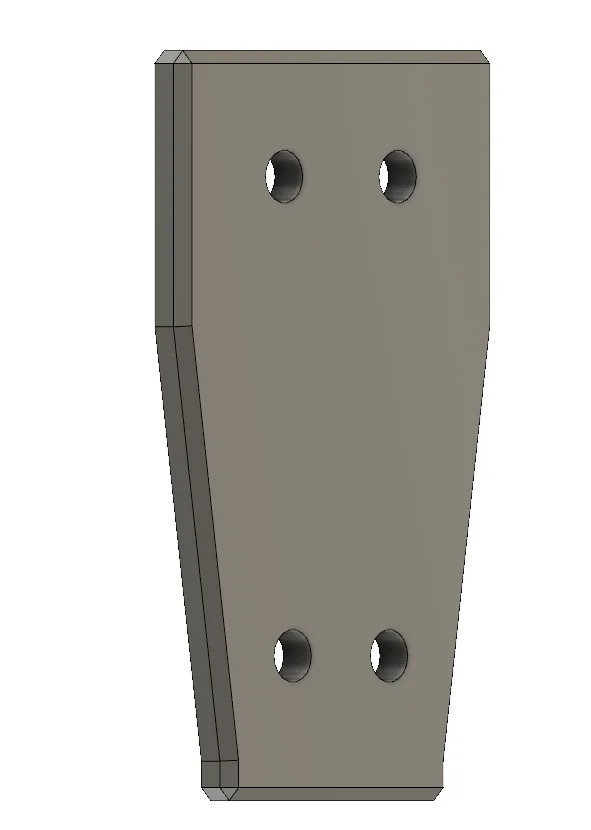
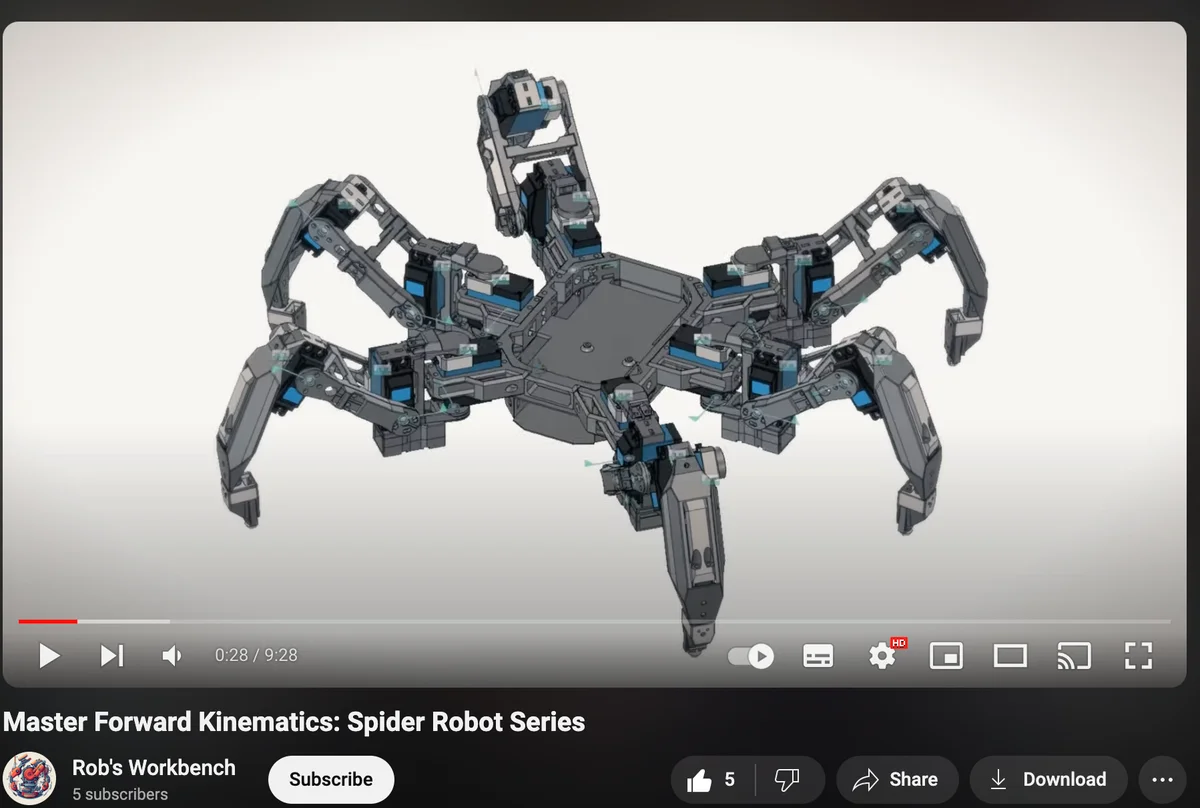
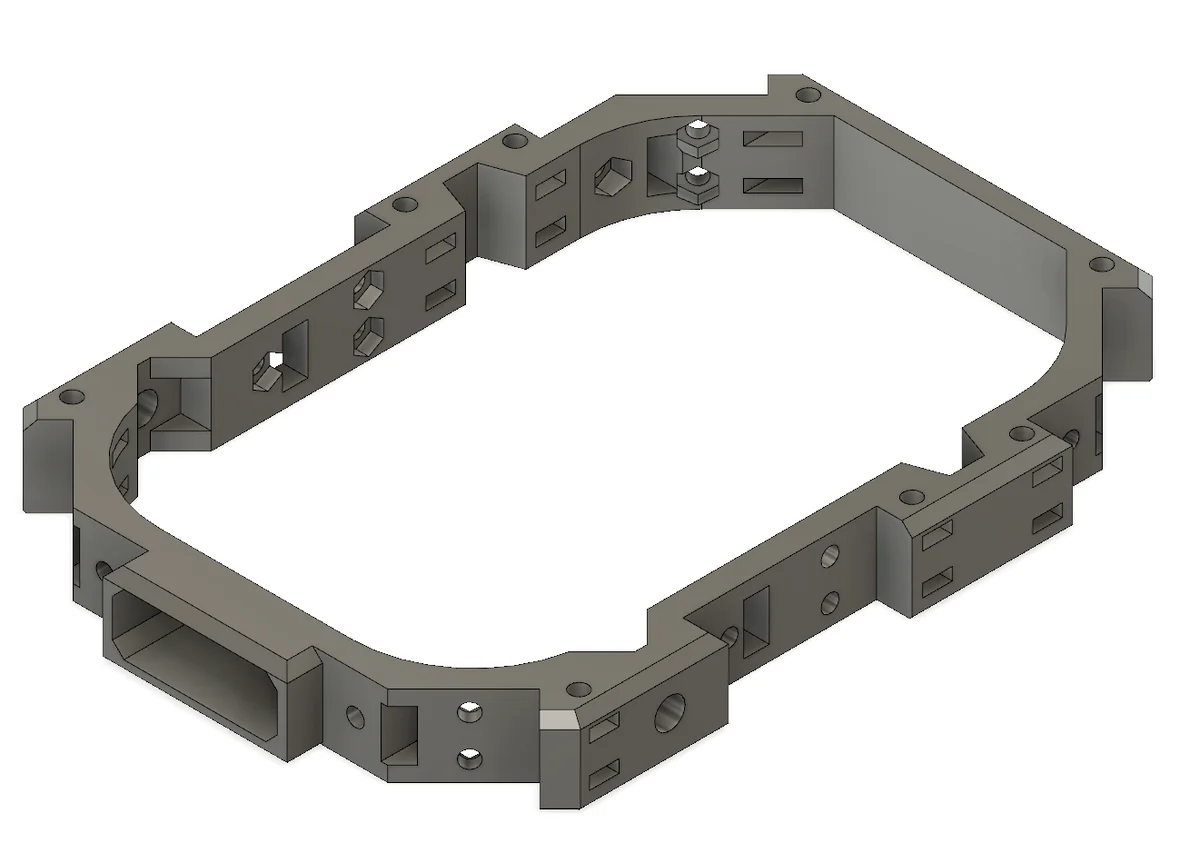
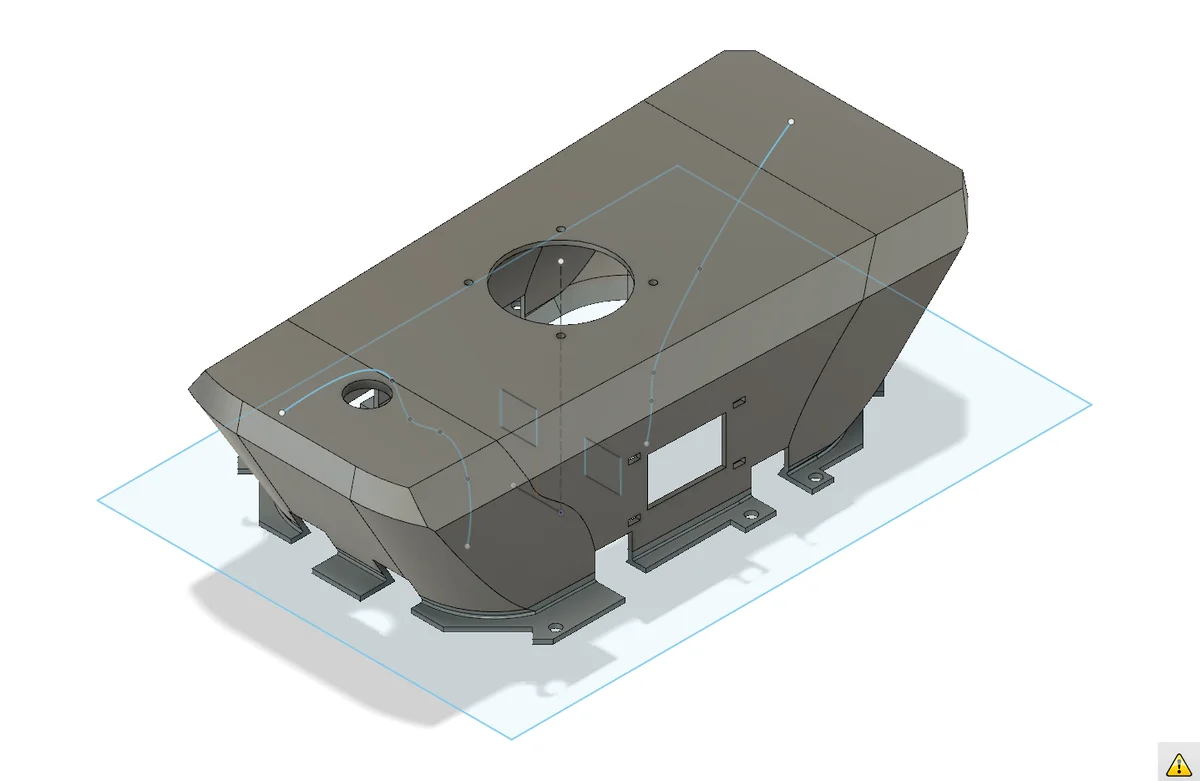
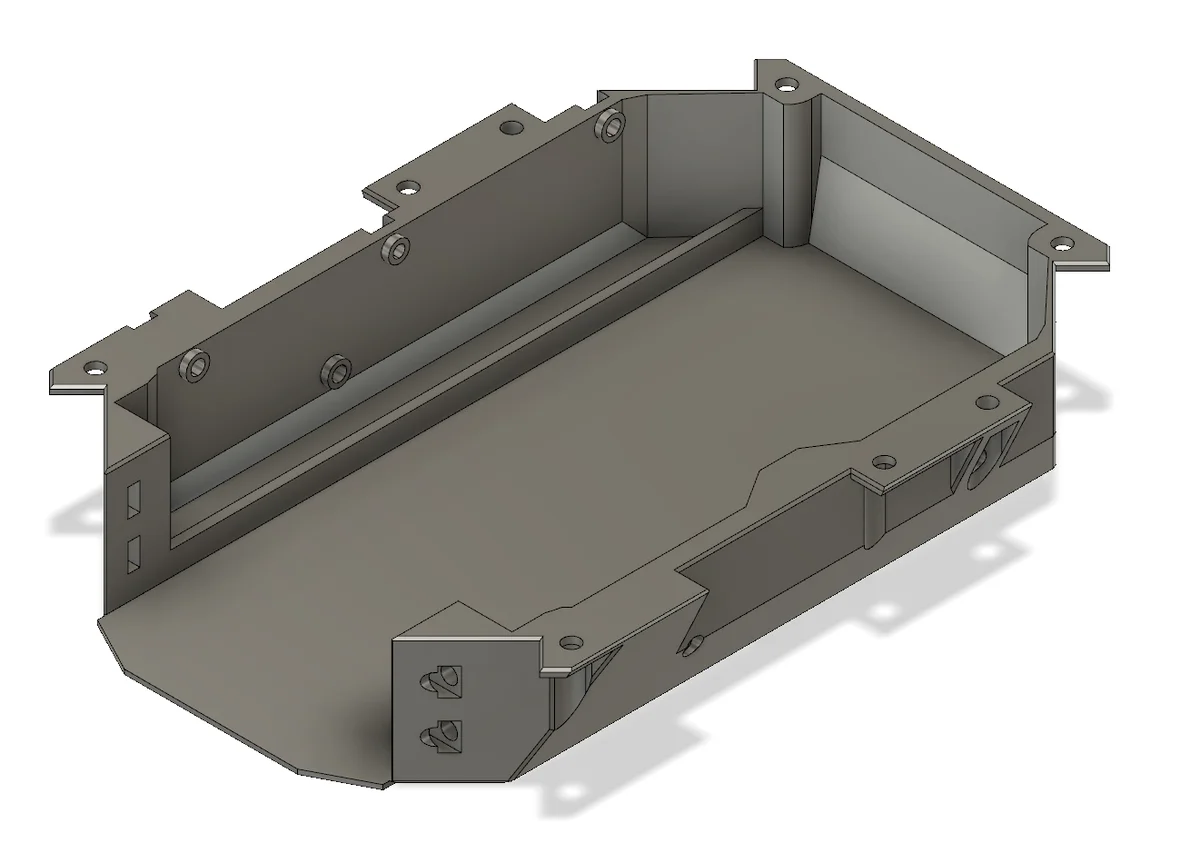
ArachnoBot is a 3D-printed hexapod spider robot with 18 degrees of freedom — three joints per leg across six legs. Built around a central frame with six symmetrical legs, it uses standard hobby servos for all joints. The project provides complete STL files for every structural component: the frame, central servo holders, side servo holders, coxa links, femur links, tibia tips, claws, electronics plate, controller plate, power compartment, and carapace.
Source: https://github.com/robs-tech-workbench/hexapod_spiderbot_model
The design is modular — a carapace plate covers the body electronics, the power compartment provides protected battery mounting, and a push-fit stand allows the robot to rest in a stable neutral position. Assembly documentation and BOM are provided in the README.
The design is inspired by the MakeYourPet community hexapod designs by Discord user "amelendez8", who contributed the leg geometry that enables smooth multi-gait locomotion. The original inspiration comes from the MakeYourPet project, adapted and extended for this build.
At 25 unique printable parts covering every leg segment and body panel, this is a complete hexapod kit that teaches hexapod kinematics, servo coordination, and 6-legged gait planning.
License: MIT.
Install Notes
This repository is primarily mechanical CAD files (FreeCAD, STL) with minimal software. Servo control code, if any, lives in a separate or forked repository. The orobot Program code is a reference stub only. To run this robot, find the corresponding firmware repo and adapt the serial bridge code in this Program's editor to match the actual command protocol.
🖨 Print Files (25)
CarapaceBack.stl
CarapaceFront.stl
CarapaceMid.stl
Claw.stl
ControllerPlate.stl
CoxaSide1_625ZZ.stl
CoxaSide2_8holes.stl
ElectronicsPlate.stl
FemurSide1_625ZZ.stl
FemurSide2_8Holes.stl
Frame.stl
FrameCenterServoHolder.stl
Required Hardware
| Part | Qty | Notes |
|---|---|---|
| Servo motor (standard) | 18 | 3 per leg × 6 legs |
| 2S LiPo battery | 1 | Main power |
| Microcontroller board | 1 | ESP32 or Arduino Mega |
| Servo driver board | 1–2 | PCA9685 or equivalent |
| M3 bolts + nuts | ~80 | Frame assembly |
| Micro switch | 6 | Leg tip contact feedback |
| PLA filament | ~500g | Standard 0.2mm layer height, 20–30% infill |
| TPU filament | ~50g | Claw components only — requires flexible material |
| 625ZZ bearings | 12 | Coxa and femur joints |
Explore similar robots