Microduck
 B
Acerca de este programa
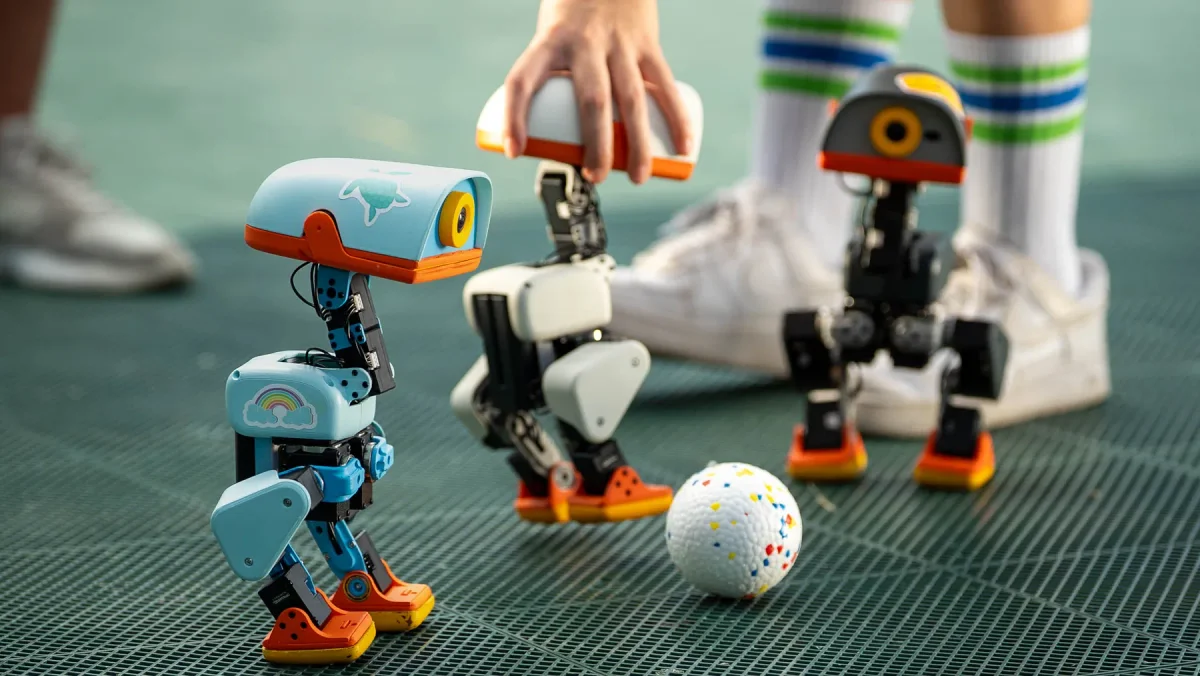
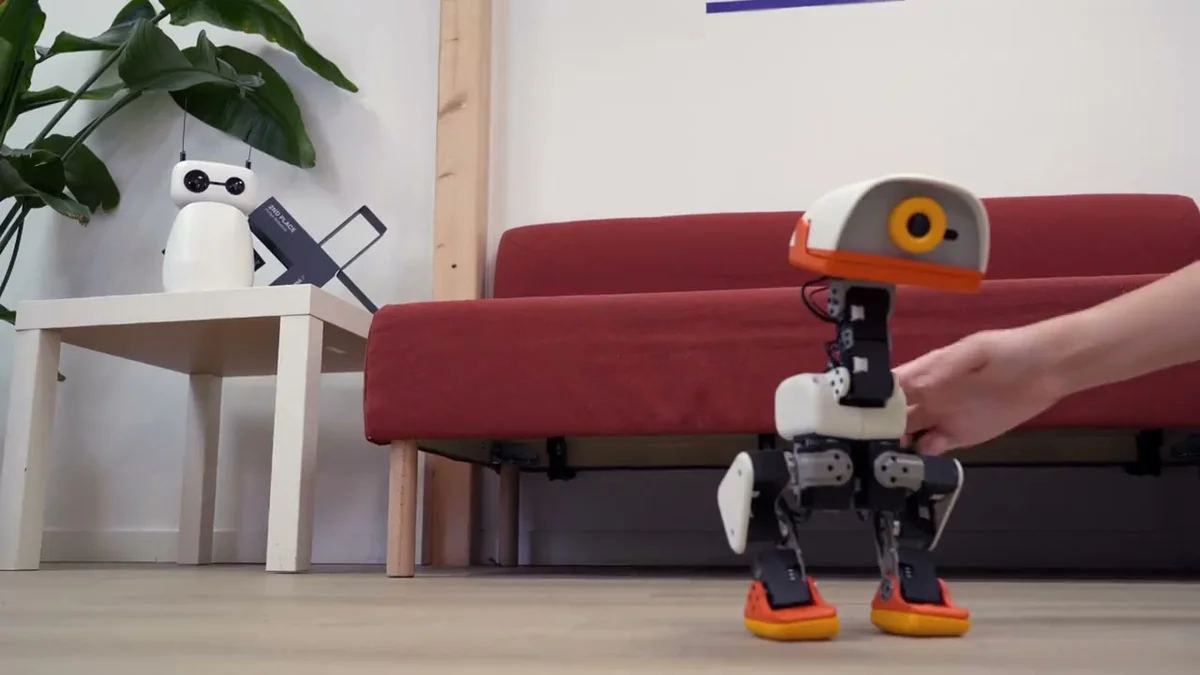
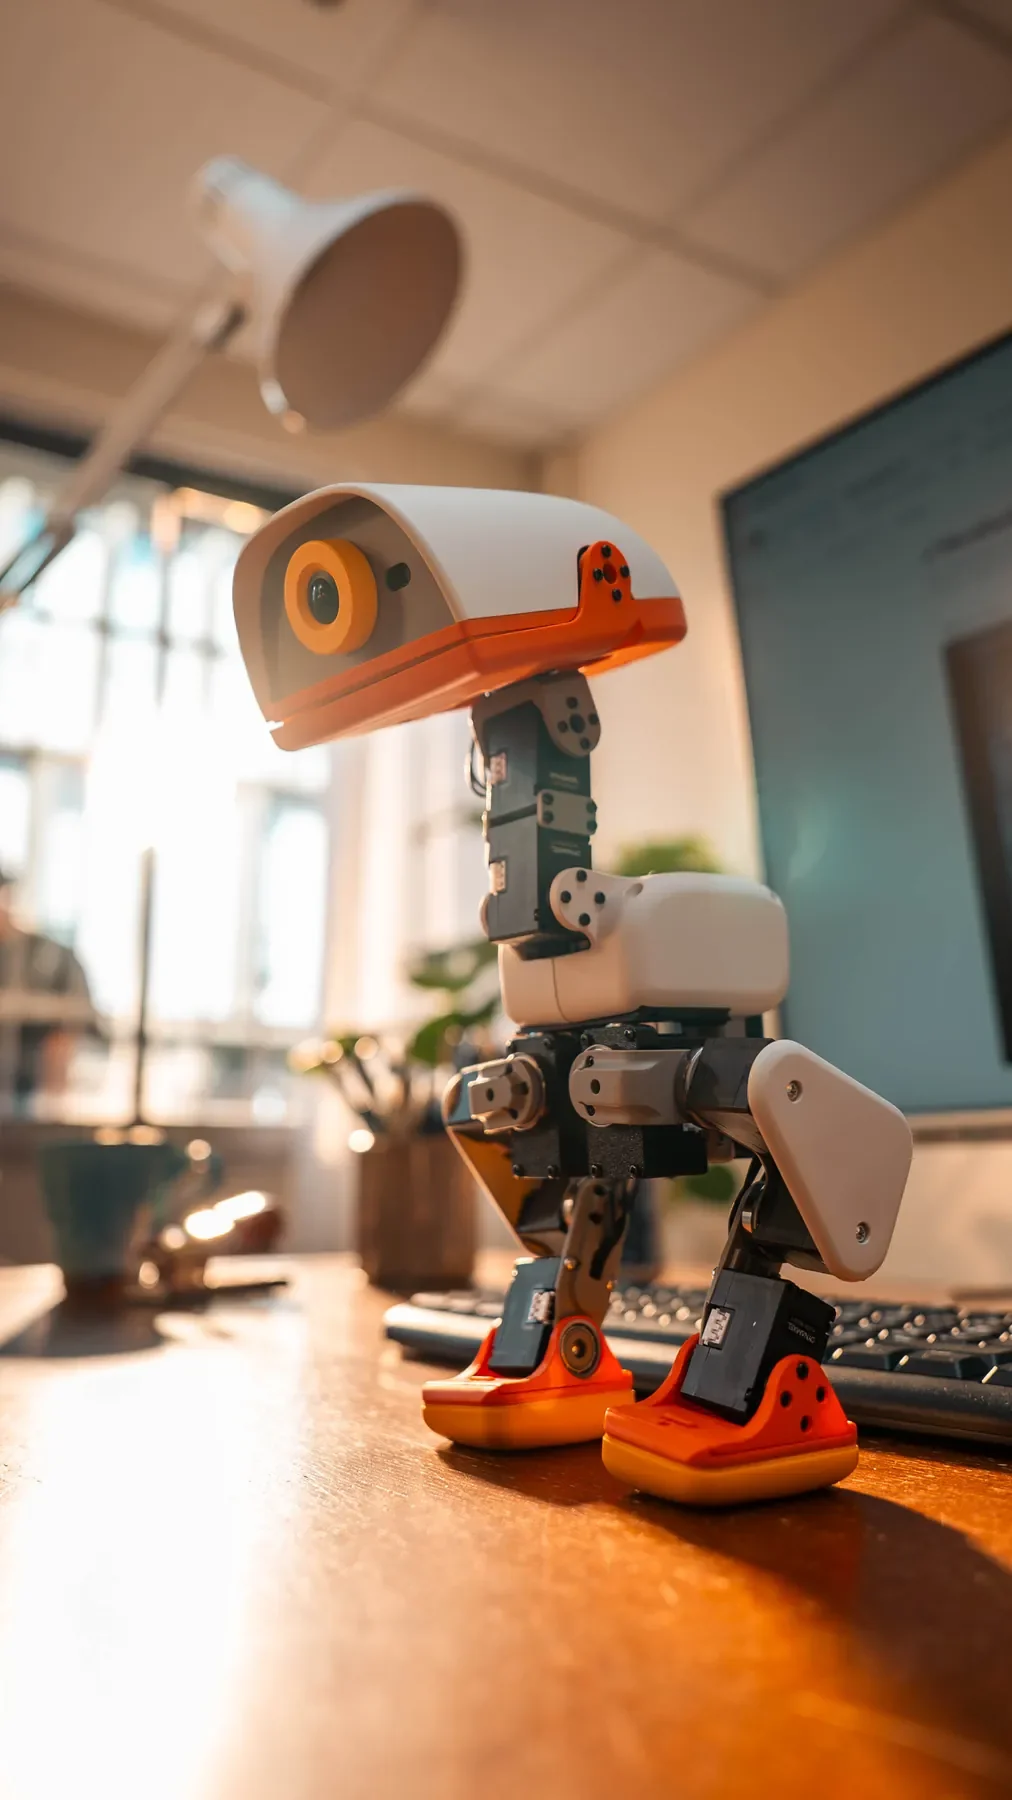
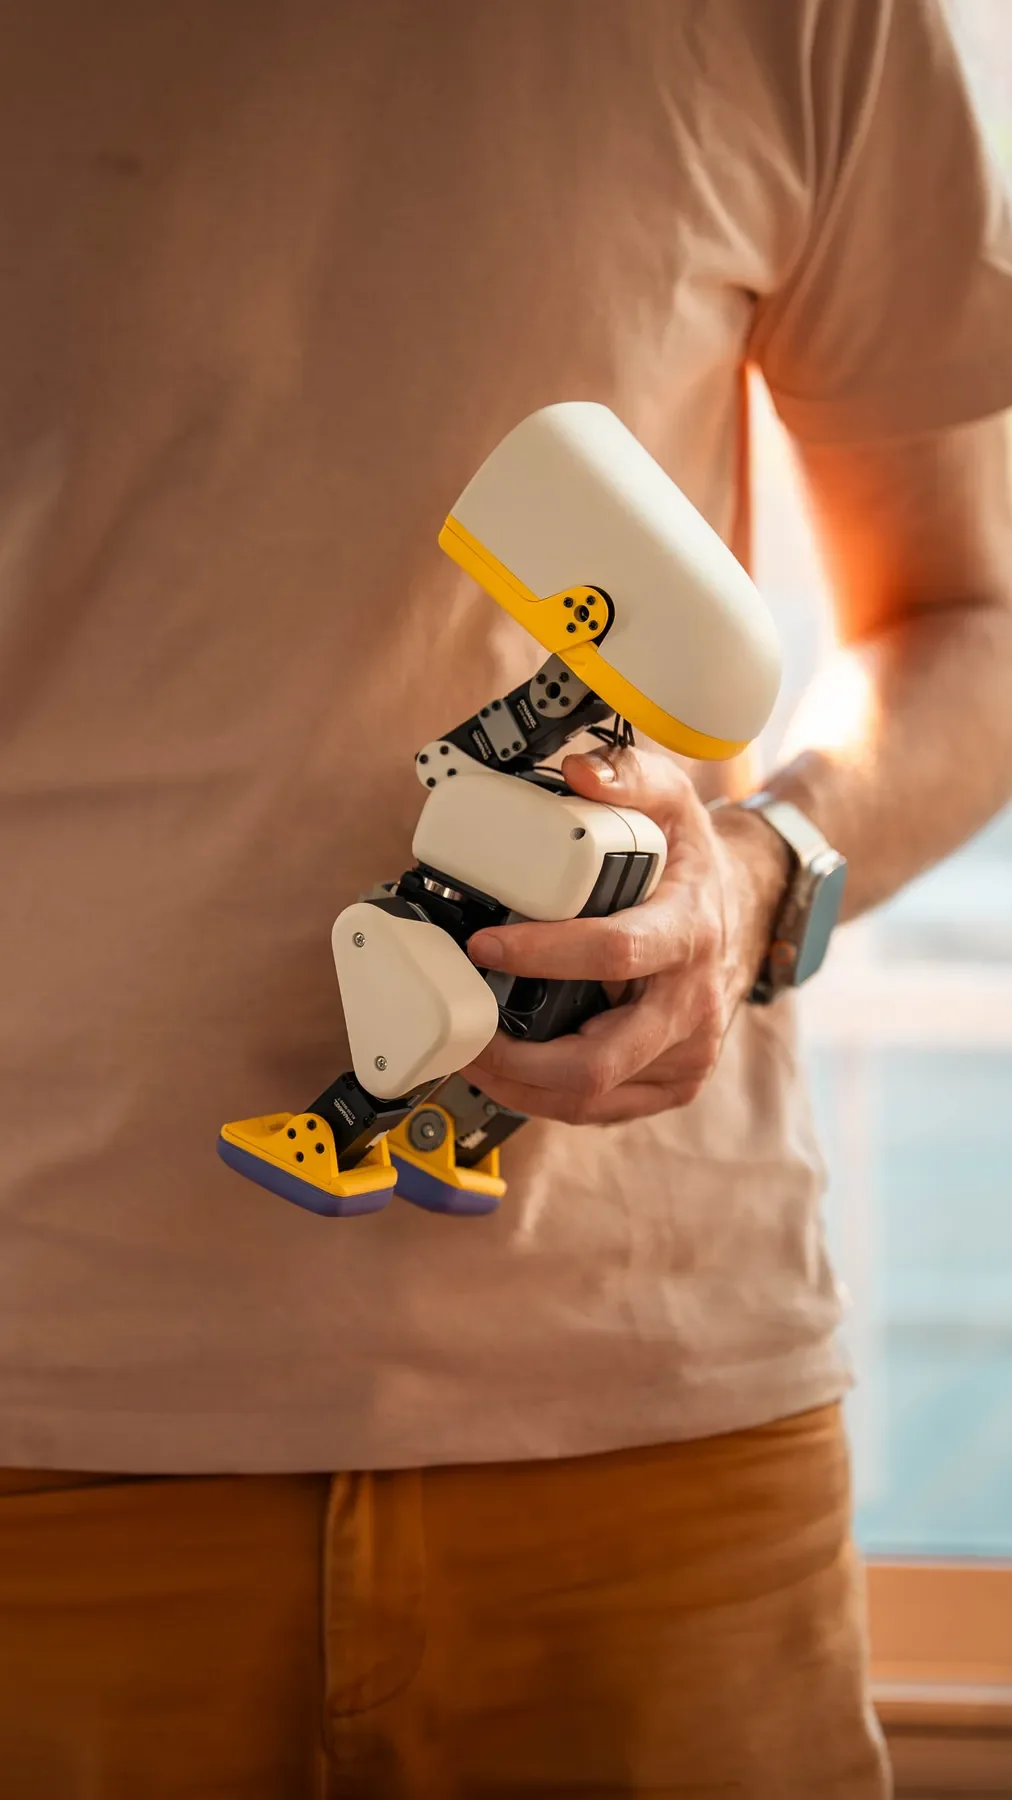
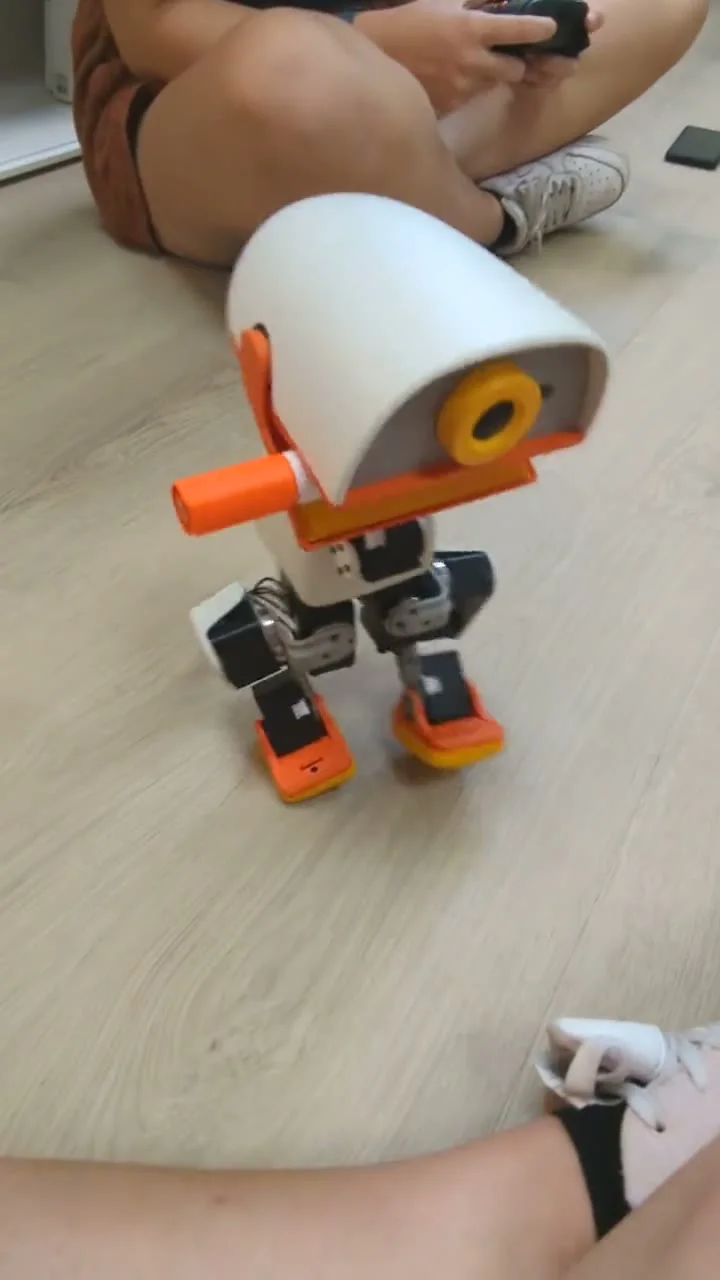
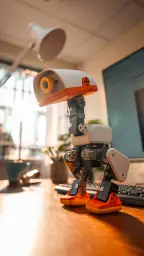
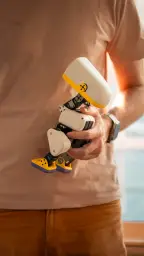
Microduck is a tiny bipedal robot — about 25 cm and 800 g — that walks, rolls, picks things up, and stands itself back up using reinforcement-learning policies. Fourteen Dynamixel XL330 servos are driven by neural policies at 50 Hz on an onboard computer, alongside an IMU, a camera, and audio.
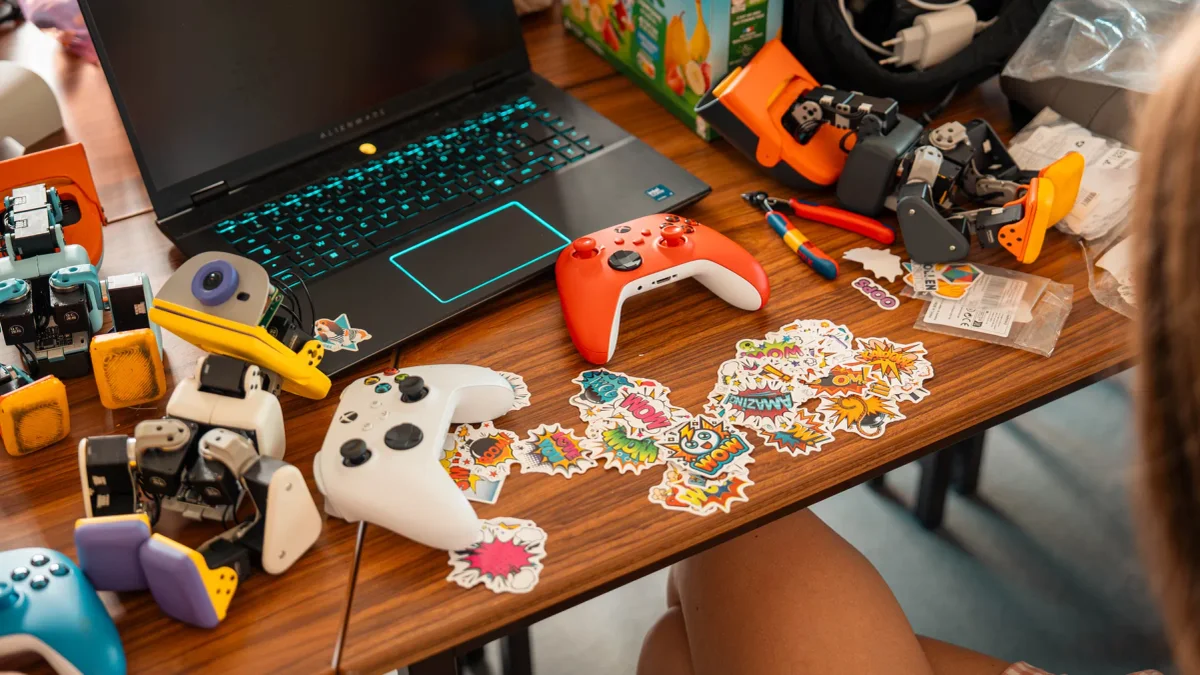
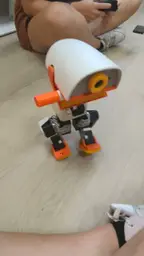
Pick up a gamepad and drive it; put wheels on and it loads a different "brain"; knock it over and it gets back up. It also sits, kicks a ball, and quacks in a voice of its own.
Open source, but you assemble it yourself
Microduck is Apache-2.0 open source, and that license covers more than the code — the sim + 3D models, the electronics, and the setup docs are all published across Pollen Robotics GitHub:
- Code / brain: pollen-robotics/microduck — the Rust daemons that run the policies.
- 3D models + RL sim: microduck_rl — the mjlab assets; the printable STLs on this page are derived from these sim meshes.
- Electronics — RPI Robot HAT: elec_RPI_Robot_HAT — a full KiCad project with production gerbers, BOM and pick-place files in the production/ folder, so you can order the board yourself (IMU, Dynamixel TTL/485, audio).
- Build a dev board: install-dev.md — bring-up from a blank board.
The catch: there is no single bill of materials or step-by-step build guide, exact part variants and fasteners are not specified, and the 3D models + parts list surfaced here are derived — reconstructed from the sim and schematics, so treat them as a starting point (possibly untested or incomplete). The only directly-supported way to get a working Microduck is the vendor kit.
Get a ready-made Microduck at pollen-robotics.com/microduck.
Source: https://github.com/pollen-robotics/microduck · Creator: Pollen Robotics · License: Apache-2.0
🖨 Archivos de impresión (29)
ankle_left.stl
ankle_right.stl
bottom_head_shell.stl
face_part.stl
foot_left.stl
foot_right.stl
hip_l.stl
jaw.stl
jaw_soft.stl
left_shell.stl
left_upper_leg.stl
leg.stl
⚠️ Reconstructed BOM — Pollen publishes no official parts list for Microduck. This is derived from the open-source sim assets, the RPI Robot HAT schematics, and the dev-board docs. Quantities and exact variants are inferred — verify before ordering. The directly-supported path is the vendor kit.
| Part | Qty | Notes |
|---|---|---|
| Dynamixel XL330 servo (likely XL330-M288-T) | 14 | 5 per leg (hip yaw/roll/pitch, knee, ankle) + 4 neck/head; sim forcerange ≈0.96 N·m → higher-torque variant. Not sold on Amazon at a sane price — order direct from the ROBOTIS e-shop ($23.90 ea, in stock, ships DHL from Korea) |
| Raspberry Pi Zero 2 W | 1 | open/sim compute (the commercial kit uses a Rockchip RK3566). The linked kit is in stock and bundles the 40-pin header the HAT needs. Amazon marks the board up heavily, but authorised resellers are perpetually backordered, so this is the only source that actually ships today |
| RPI Robot HAT board | 1 | Fab it yourself: download PCB01186-C1 gerber zip and upload it at JLCPCB instant quote. For assembly, also supply BOM + POS/CPL |
| BMI088 IMU | 1 | on the HAT board — placed by the assembler from the HAT BOM/POS files, not bought separately |
| Camera module + M12 lens | 1 | |
| Sony NP-F970 battery | 1 | |
| Speaker | 1 | audio via the HAT (TLV320AIC3104 + PAM8406) |
| Ball bearings 22×16×4 mm | 2+ | Non-standard bore (ISO 6703 is 17×23×4). Amazon carries the exact size but only as a pricey single-piece listing — Seeed / AliExpress are far cheaper in quantity |
| 3D-printed parts | 33 | see Print Files — derived from the sim meshes; ~240 cm³, 1 kg spool is plenty |
| Fasteners (M2 / M2.5) | assorted | not specified upstream |
Explorar robots similares