Papaya Pathfinder
 B
Acerca de este programa
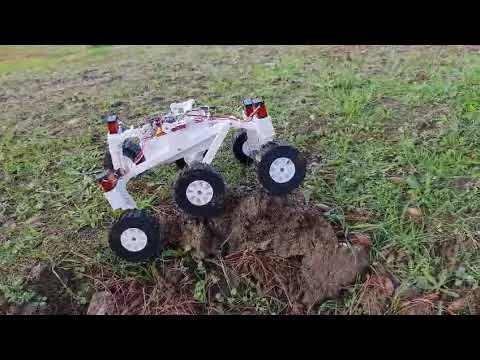
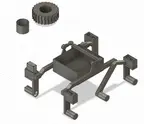
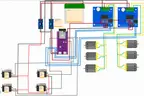
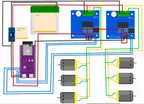
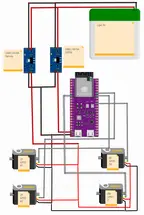
Papaya Pathfinder is an open-source, fully 3D-printable rocker-bogie rover built around an ESP32. Where the catalog's other rocker-bogie rovers (Sawppy, ExoMy) lean on stepper motors and more elaborate electronics, Papaya Pathfinder is the cheap, WiFi-first variant: 6x GA25 DC gear motors (3 per side, gang-driven through 2x BTS7960 43A drivers) turn the wheels, and 4x MS24 servos steer the front/back corners — all controlled straight from an ESP32 over a plain HTTP API, no RTOS or ROS stack required.
All structural parts print in PETG or PLA, tires in TPU, and everything bolts together with M3 hardware. The design ships in two sizes:
- Papaya Pathfinder (this program's focus): 6x GA25 motors, 2x BTS7960 drivers, 4x MS24 steering servos, LiPo 3S power.
- Papaya Pathfinder Mini: a smaller variant built around an ESP32-CAM/ESP32-S3-CAM for live video streaming, 6x N20 motors, LiPo 2S power.
Firmware supports two control paths — flash whichever matches your radio setup:
firmware-wifi— HTTP API, driven by the included Python desktop controller (gamepad +pygame) or the Android controller app (Kotlin/Jetpack Compose), both in the source repo.firmware-elrs— direct RC control over ExpressLRS, no phone/laptop needed.
The repo also includes an experimental vision-language "AI pilot" script (ia-controller/) that polls the Mini's camera feed and drives via a local VLM — worth a look if you want to extend this past manual control.
This orobot.io program is a learning-stub entry point, not a working remote for your physical rover: Papaya Pathfinder runs its own custom ESP32 Arduino firmware speaking a plain HTTP API, not the orobot device protocol, so the generated code/config here only illustrates how the joystick + steering controls would map onto orobot's API. To actually drive a build, flash the firmware from GitHub and use the project's own desktop or Android controller.
Source: https://github.com/tronxi/papaya-pathfinder (by tronxi)
License: Apache License 2.0 (the repo's single top-level LICENSE file covers the firmware, apps, CAD/STEP, and STL files alike — there is no separate CC-BY-licensed hardware split in this repo as of the commit ingested here).
STLs, STEP CAD, wiring diagrams and BOM tables: pathfinder/ directory. Also listed on Printables and demoed on YouTube (hero/gallery photos here are frames from that demo video, used with attribution).
🖨 Archivos de impresión (13)
arm_left.stl
arm_right.stl
body.stl
differential_bar.stl
differential_link_left.stl
differential_link_right.stl
horn_adapter.stl
motor_mount.stl
pivot_left.stl
pivot_right.stl
rim.stl
rim_hexagonal.stl
Hardware requerido
| Item | Qty | Notes |
|---|---|---|
| ESP32 (dev board) | 1 | Main controller |
| ELRS receiver | 1 | Only needed if flashing firmware-elrs instead of firmware-wifi |
| BTS7960 43A motor driver | 2 | One per drive side (gangs 3 GA25 motors together) |
| GA25 DC gear motor | 6 | Drive motors, 3 per side |
| MS24 servo | 4 | Corner steering (front-left/right, back-left/right) |
| LiPo 3S battery | 1 | Main power |
| UBEC 5V/3A | 1 | Logic supply for ESP32 |
| UBEC 6V/8A | 1 | High-current supply for the 4 steering servos |
body.stl | 1 | Main chassis (PETG/PLA) |
arm_left.stl / arm_right.stl | 1 each | Suspension arms (PETG/PLA) |
pivot_left.stl / pivot_right.stl | 1 each | Pivot mounts (PETG/PLA) |
differential_bar.stl | 1 | Central rocker-bogie differential bar (PETG/PLA) |
differential_link_left.stl / differential_link_right.stl | 1 each | Links from differential bar to suspension arms (PETG/PLA) |
motor_mount.stl | 4 | GA25 motor mounts on steering arms (PETG/PLA) |
horn_adapter.stl | 4 | Servo horn adapters — print horizontally for strength (PETG/PLA) |
rim.stl | 6 | Standard wheel rim, D-shaft mount (PETG/PLA) |
rim_hexagonal.stl | 6 | Recommended rim upgrade — needs 12mm brass hex adapters, resists shaft stripping (PETG/PLA) |
tire.stl | 6 | Tires (TPU) |
Explorar robots similares