LeLamp
 B
このプログラムについて
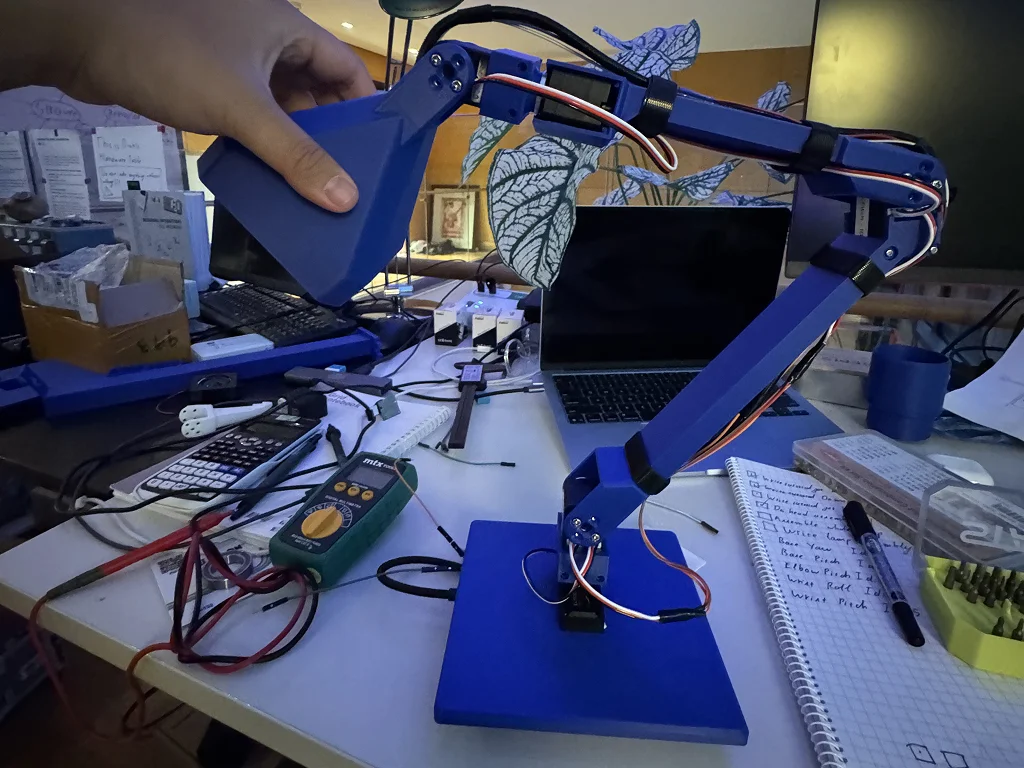
LeLamp is an open-source, expressive robot lamp with a 5-axis articulated arm, a Pi Camera "eye", a 24-LED programmable matrix face, and onboard microphone/speaker for voice interaction. It's directly inspired by Apple's ELEGNT research on expressive functional robot movement, built by Human Computer Lab.
The arm carries 5 Feetech STS3215 bus servos (base yaw, base pitch, elbow pitch, wrist roll, wrist pitch) driven from a Waveshare TTL servo driver, with a Raspberry Pi in the lamp head running camera, audio, and LED subsystems. The official runtime supports recording and replaying custom expressive movements (built on the LeRobot framework), so the arm can be puppeted by hand and play the motion back later.
Source & attribution
- Hardware/CAD/BOM: humancomputerlab/LeLamp — licensed GPL-3.0.
- Runtime/control software: humancomputerlab/lelamp_runtime — no LICENSE file is present in this repository as of onboarding (2026-09-13). Treat the runtime code's usage rights as unclear/all-rights-reserved by default until the maintainers add a license; check the repo before redistributing or building on top of it.
- Created by Human Computer Lab. The team has announced a closed-source version planned for a later release — this open build may not track future upstream changes.
Build specs (from source docs): ~$260–310 estimated cost (US, reference pricing) · 8–12 hours build time · Intermediate/Advanced skill level (soldering, 3D printing, Linux/SSH). 5 degrees of freedom.
What's in this program: an operator-panel learning stub (buttons + slider wired to the real named-motor API) so you can jog the 5 joints in-browser, plus the 7 unique 3D-printed body parts (arm segments, base, head, diffuser) and a cost-annotated BOM. Full firmware, calibration, recording/replay, camera, audio, and LED control live in the runtime repo linked above — this orobot.io program is an entry point, not a port of that stack.
Note on hardware in this program: LeLamp's servos and camera/audio/LED peripherals are custom BYOD hardware (Feetech STS3215 bus servos via a Waveshare driver, plus a Raspberry Pi in the head) — not orobot's native WiFi-motor/WiFi-camera hardware. The in-browser control demo here drives placeholder motor slots so you can see the intended interface; real hardware control requires following the source build guide and running lelamp_runtime on the Pi.
必要なハードウェア
| Item | Qty | Unit Price | Total | Notes |
|---|---|---|---|---|
| Feetech ST3215 Servo | 5 | $23.99 | $119.95 | 5x bus servos, one per joint (base yaw, base pitch, elbow pitch, wrist roll, wrist pitch) |
| Waveshare Servo Driver Board | 1 | $10.99 | $10.99 | TTL bus servo driver/adapter |
| Raspberry Pi (Zero 2 W in the reference build; BOM lists Pi 4 as a "more capable" option) | 1 | $59.99 | $59.99 | Can be replaced with a Pi 3B/4/5 |
| 32GB MicroSD Card | 1 | $11.17 | $11.17 | |
| ReSpeaker 2-Mics Pi HAT | 1 | $14.99 | $14.99 | Microphone array for voice interaction |
| Speaker (JST-PH2.0) | 1 | $7.99 | $7.99 | |
| 8x5 WS2812B LED Matrix | 1 | $8.99 | $8.99 | 24-programmable-LED expressive display |
| 5V 2A DC Power Supply | 1 | $8.29 | $8.29 | |
| Type-C to MicroUSB Cable (90°, ≥1m) | 1 | $7.50 | $7.50 | Routes power from base to head |
| Thin LAN/Ethernet Cable | 1 | $7.99 | $7.99 | Data link from body to head |
| 3D Printed Parts (PLA+/PETG) | 1 set | $30.00 | $30.00 | 7 unique parts — see files on this program |
| 16mm M3 & 4mm M2 Screws | 1 | $22.79 | $22.79 | |
| M2 & M3 Heat Inserts | 1 | $15.79 | $15.79 | Optional if printer tolerances are tight |
| Male Pin Header | 1 | $5.49 | $5.49 | |
| Male-to-Female Jumper Wires | 1 | $9.99 | $9.99 | |
| Total (source estimate, US) | $310.64 | Source: LeLamp BOM spreadsheet — reference links only, buy locally for best price |
似たロボットを探す