


Just1 Mecanum Robot
 B
✓ Links überprüft Aug 31, 2026
Registrieren, um zu installierenÜber dieses Programm
66 stars on GitHub.
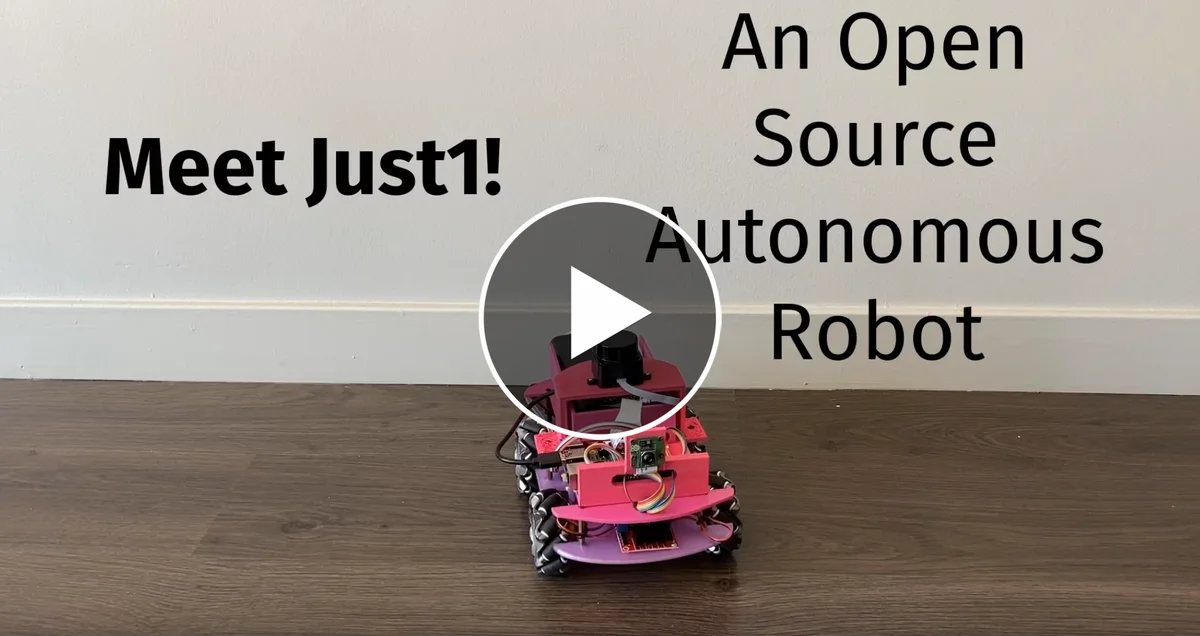
Just1 is an open-source autonomous mobile robot built for ~$250, designed as an accessible learning platform for ROS2, SLAM, and autonomous navigation. It uses four mecanum wheels driven by TT motors, enabling holonomic (omnidirectional) movement — it can drive forward, strafe sideways, or rotate in place without turning.
Source: https://github.com/NRdrgz/Just1
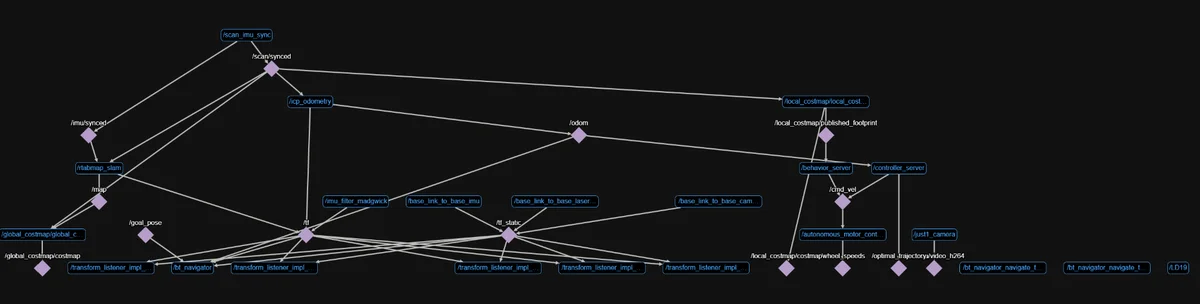
The robot navigates autonomously using a 2D LiDAR (LD19 model) for obstacle detection and SLAM-based mapping. RTAB-Map handles simultaneous localization and mapping, while Nav2 manages path planning and obstacle avoidance. A Raspberry Pi Camera provides visual data, and an IMU with Madgwick filter provides orientation estimates.
Just1 operates in two modes: autonomous navigation with LiDAR-based obstacle avoidance, or manual gamepad control (Nintendo controller via Bluetooth). The software stack runs on ROS2 Jazzy with Foxglove Studio for real-time sensor visualization and monitoring.
Performance specs tested on flat indoor surfaces: maximum forward speed 0.6 m/s, lateral speed 0.5 m/s, rotational speed 3.5 rad/s (204°/s). The LiDAR-based approach allows reliable operation in complete darkness, unlike camera-only SLAM systems.
The chassis is fully 3D-printable — top plate, bottom plate, motor holder, LiDAR mount, and Raspberry Pi bracket are all included. The project is designed to be built and extended: planned improvements include camera+LiDAR fusion, wheel encoders for improved odometry, an SO-101 arm attachment, and NVIDIA Isaac Sim simulation support.
Hardware: Raspberry Pi 4, LD19 2D LiDAR, Raspberry Pi Camera, IMU, 4× mecanum wheels with TT motors. Open-source under MIT license with full build guides and blog articles.
🖨 Druckdateien (5)
Holder-Motor.STL
Car-chassis---top.STL
LD19-Holder.STL
Car-chassis-bottom.STL
Raspberry-Holder.STL
| Item | Qty | Unit Cost | Notes |
|---|---|---|---|
| Raspberry Pi 4 (2GB or 4GB) | 1 | $45 | Main compute |
| Pi 4 USB-C 15W power supply | 1 | $10 | (inferred) |
| 32GB microSD card | 1 | $8 | (inferred) |
| TT gear motor with wheel | 4 | $4 | Mecanum-compatible TT motors |
| Mecanum wheel set 60mm (TT-compatible) | 1 | $20 | 4 wheels |
| L298N or TB6612 dual H-bridge | 2 | $6 | Drive 4 motors |
| Raspberry Pi Camera Module v2 | 1 | $25 | |
| 2D LiDAR (RPLIDAR A1 / LD06) | 1 | $80 | LD06 is the budget option |
| MPU6050 IMU | 1 | $5 | (inferred — README says IMU) |
| 18650 battery holder + cells (2S or 3S) | 1 | $20 | (inferred) |
| 18650 cells | 3 | $7 | (inferred) |
| Buck converter 5V 3A | 1 | $5 | (inferred — Pi from battery) |
| Jumper wires + Dupont kit | 1 | $8 | (inferred) |
| Acrylic chassis plate | 1 | $10 | (inferred — flat platform) |
| M3 standoffs + screws kit | 1 | $10 | (inferred) |
Ähnliche Roboter entdecken