


Berkeley Humanoid Lite
 B
✓ Enlaces verificados Aug 31, 2026
Solo guías y lista de materiales: el firmware de orobot aún no es compatible con este hardware.
Regístrate para explorarAcerca de este programa
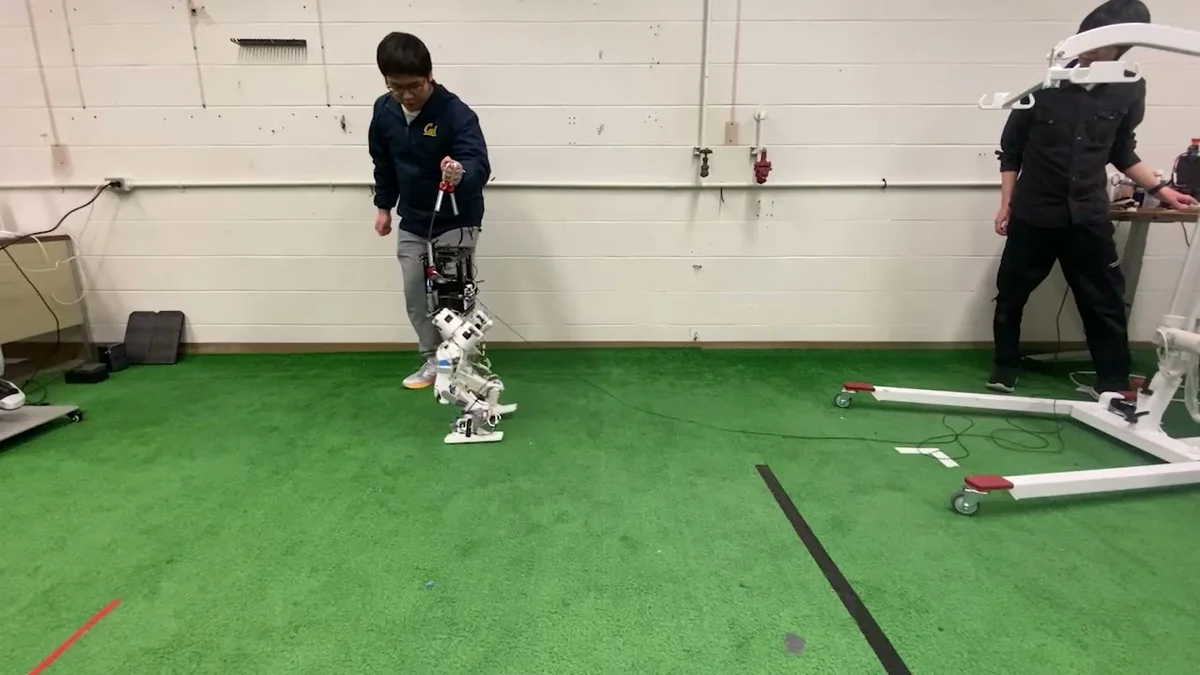
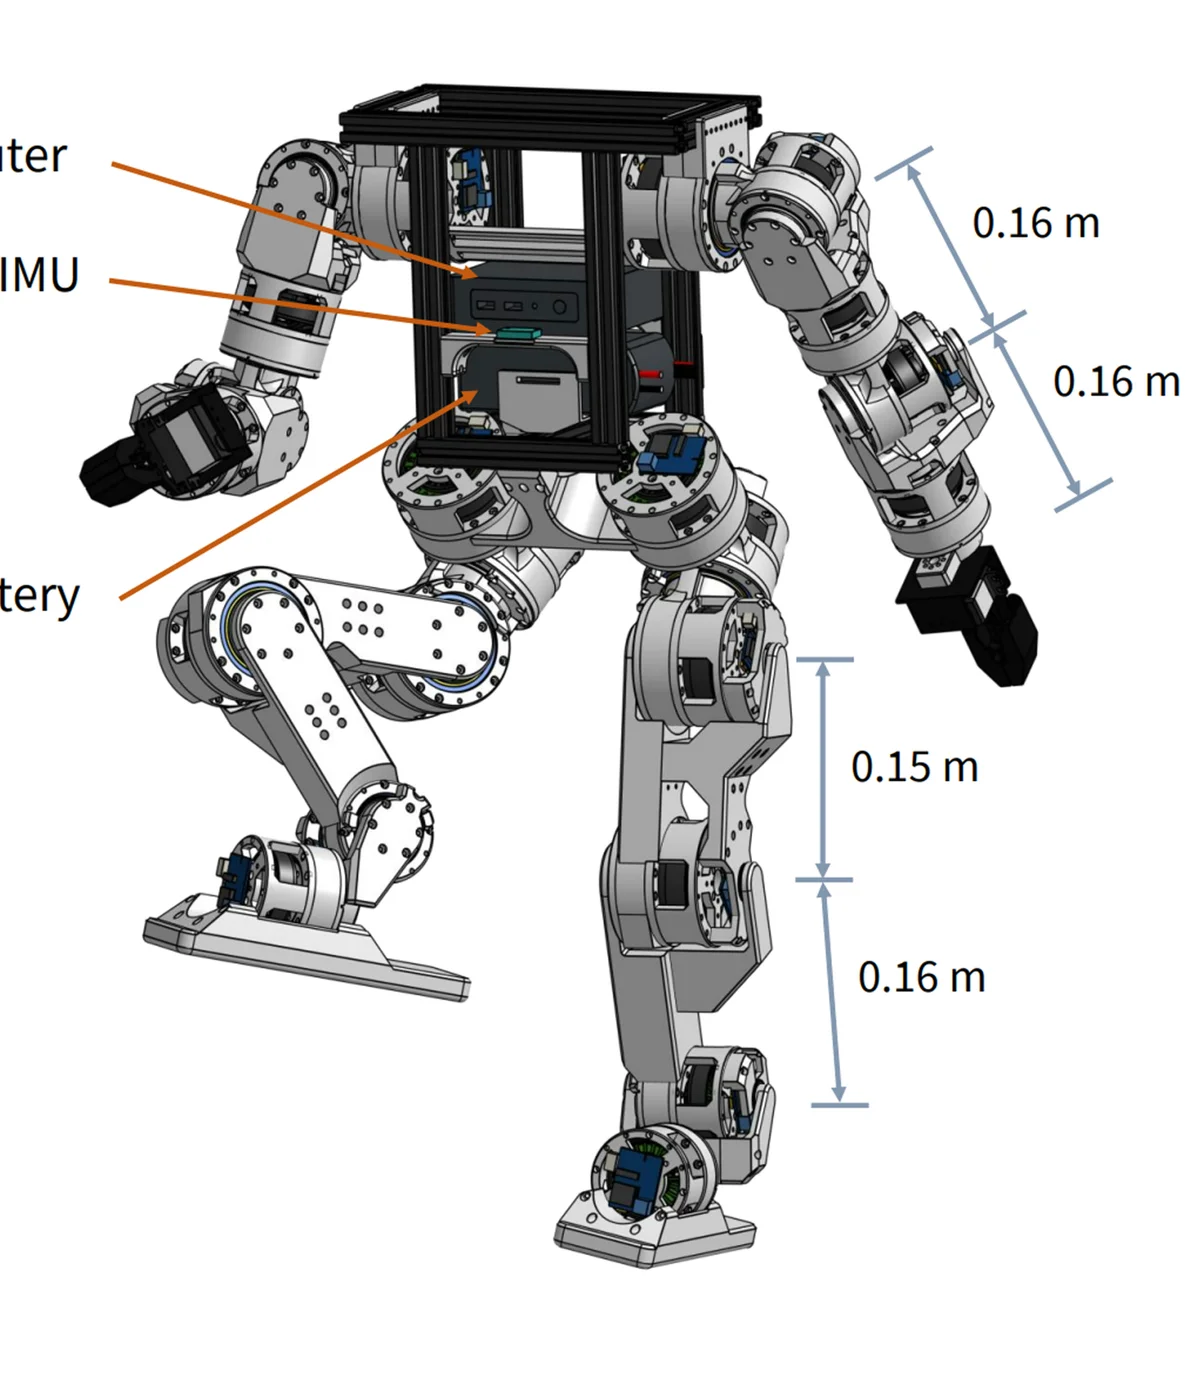
Berkeley Humanoid Lite is an open-source, sub-$5,000 humanoid robot from UC Berkeley's Hybrid Robotics lab — a full 22-DOF biped (12 leg joints + 10 arm joints) built around modular, fully 3D-printed cycloidal gearboxes and widely available off-the-shelf parts. It was created to democratize humanoid-robotics research: every actuator is printed and hand-assembled, the electronics are commodity, and the entire software stack — RL policy training, sim-to-sim/sim-to-real, teleoperation, and low-level control — is open.
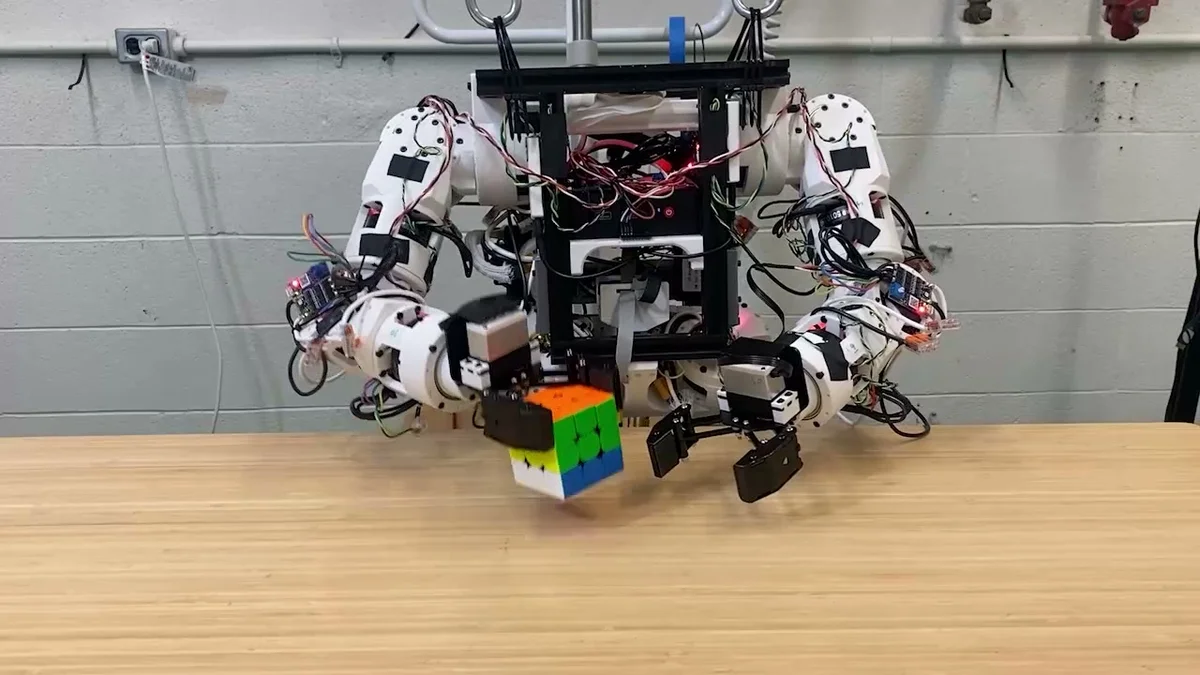
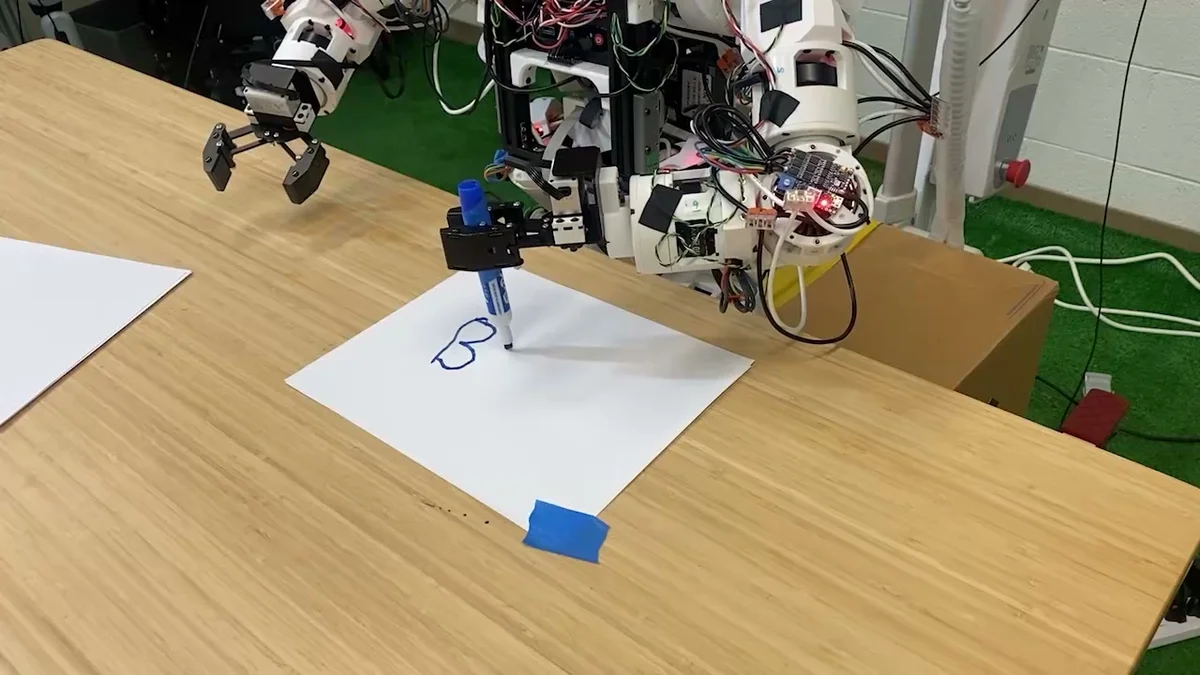
The robot walks (bipedal locomotion via a learned RL policy), and with its two 5-DOF arms and grippers it performs bimanual manipulation: solving a Rubik's cube, writing with a marker, and stacking blocks. Perception and control run on an onboard x86 mini-PC; joints connect over CAN bus through custom STM32 (B-G431B-ESC1) motor controllers running the open "recoil" firmware, with a BNO085 IMU for balance.
What this orobot program is
This is a browser-based learning interface and entry point. The in-page 3D viewer shows the robot's per-link meshes, and the Robot Operator panel drives the 22 joints through poses and demo sequences (stand, wave, squat, march) so you can understand the kinematic layout. It is not the balancing locomotion controller — that lives in the low-level repo below. Use this to learn the layout, then dive into the source to build and deploy the real thing.
Build it for real
- Paper (arXiv 2504.17249): https://arxiv.org/abs/2504.17249
- Project site: http://lite.berkeley-humanoid.org/
- Build docs (GitBook): https://berkeley-humanoid-lite.gitbook.io/docs
- Video: https://youtu.be/dIdJGkMDFl4
- Main repo (training + deploy): https://github.com/HybridRobotics/Berkeley-Humanoid-Lite
- Low-level control (CAN + RL runtime): https://github.com/HybridRobotics/Berkeley-Humanoid-Lite-Lowlevel
- CAD / URDF / MJCF / STL assets: https://github.com/HybridRobotics/Berkeley-Humanoid-Lite-Assets
Highlights
- 22 DOF — two 6-DOF legs + two 5-DOF arms, built from two modular actuator types (10× M6C12, 12× 5010)
- Fully 3D-printed actuators — cycloidal gearboxes in PLA around MAD M6C12 (150KV) and 5010 (110KV) BLDC motors
- Commodity BOM — ~$205 per M6C12 actuator, ~$154 per 5010; $4,794 for the whole robot at verified September 2026 prices (filament excluded)
- URDF / MJCF / USD descriptions included — sim-ready in Isaac Lab & MuJoCo
- RL locomotion + bimanual manipulation — trained policies (ONNX) ship in the repo
Attribution
Created by Yufeng Chi, Qiayuan Liao, Junfeng Long, Xiaoyu Huang, Sophia Shao, Borivoje Nikolic, Zhongyu Li, and Koushil Sreenath (UC Berkeley Hybrid Robotics). Code licensed MIT; hardware/CAD assets licensed CC BY-SA 4.0. This program mirrors their open-source project as a learning entry point — all credit to the original authors.
🖨 Archivos de impresión (26)
5010_Front_Ankle__Housing_Front_Ankle.stl
5010_Housing_5010__UpperArm_X_Housing_Middle.stl
5010_Housing_Ankle__Ankle_Mount.stl
5010_Housing_Ankle__Ankle_Mount_2.stl
5010_Rear_Cover__Rear_Struct.stl
6512_Housing_2020__Base_Housing_Front.stl
6512_Housing_2020__Base_Housing_Middle.stl
6512_Housing_5010__UpperArm_X_Housing_Middle.stl
6512_Housing_6512__Stopper_Y_L.stl
6512_Housing_6512__UpperLeg_X_Housing_Middle.stl
6512_Housing_Hip__Housing_Middle.stl
6512_Housing_Knee__Housing_Middle_L.stl
Hardware requerido
The Berkeley Humanoid Lite is built from 22 modular actuators of two types — 10× M6C12 (150KV) and 12× 5010 (110KV) — plus commodity electronics and an aluminum-extrusion torso. The authors' full parts sheet (US Amazon + China/Taobao links) is here.
All quantities below are for one complete robot. Every price was re-checked against its live listing on September 1, 2026. Because most fasteners and bearings only sell in packs, each row shows the pack size and how many packs you actually have to buy.
PLA filament is not part of this BOM — it is a printing input, tracked with the print files (~1,964 cm³ / ~2.4 kg for the actuator parts), not a purchased assembly component.
- Cart total (what you pay): $4,794.17
- Material value actually consumed by the robot: $4,634.80
- Original published figure: $4,350.59 — that sheet is now $443.58 low
Per-actuator cost at current prices: $205.11 (M6C12) and $154.10 (5010), up from $188.69 and $136.36.
Full robot build — actuator parts (all 22 actuators)
Derivation in parentheses = per-actuator qty × number of actuators.
| Item | Qty needed | Pack size | Packs to buy | $ / pack | Line cost | Buy |
|---|---|---|---|---|---|---|
| MAD Components M6C12 150KV (1×10) | 10 | 1 | 10 | $128.99 | $1,289.90 | link |
| MAD Components 5010 110KV (1×12) ⚠️ OUT OF STOCK | 12 | 1 | 12 | $83.99 | $1,007.88 | link |
Explorar robots similares