Aero Hand Open
 B
✓ リンク確認済み Oct 9, 2026
インストールするには登録してくださいこのプログラムについて
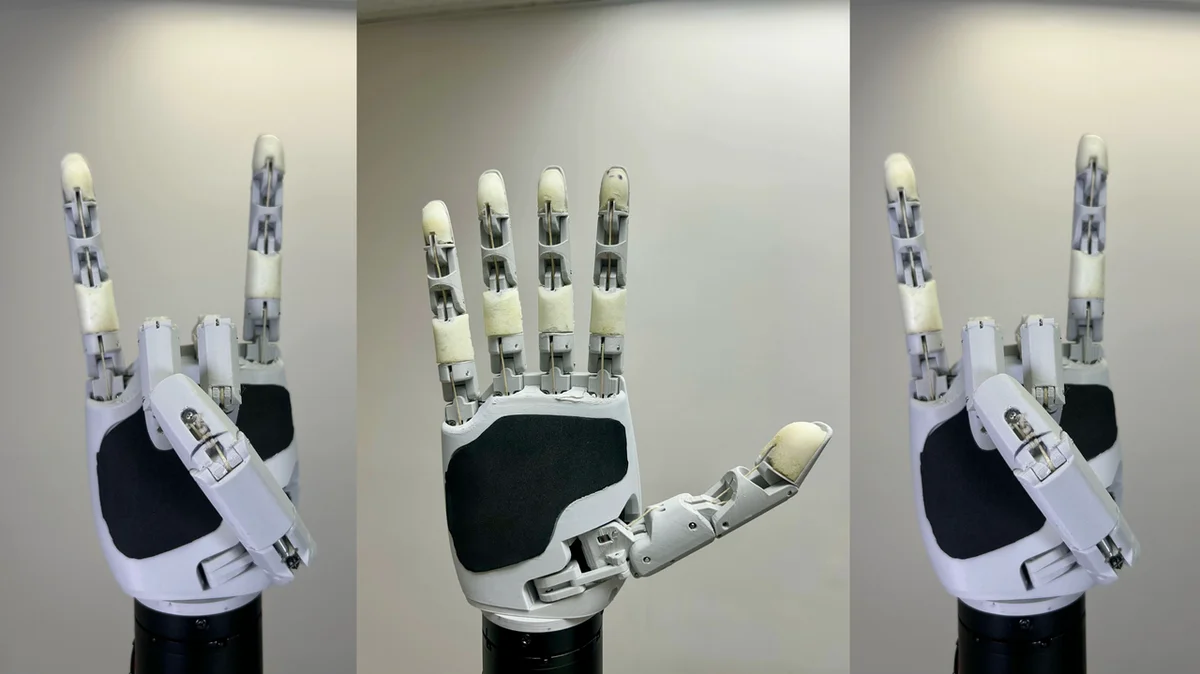
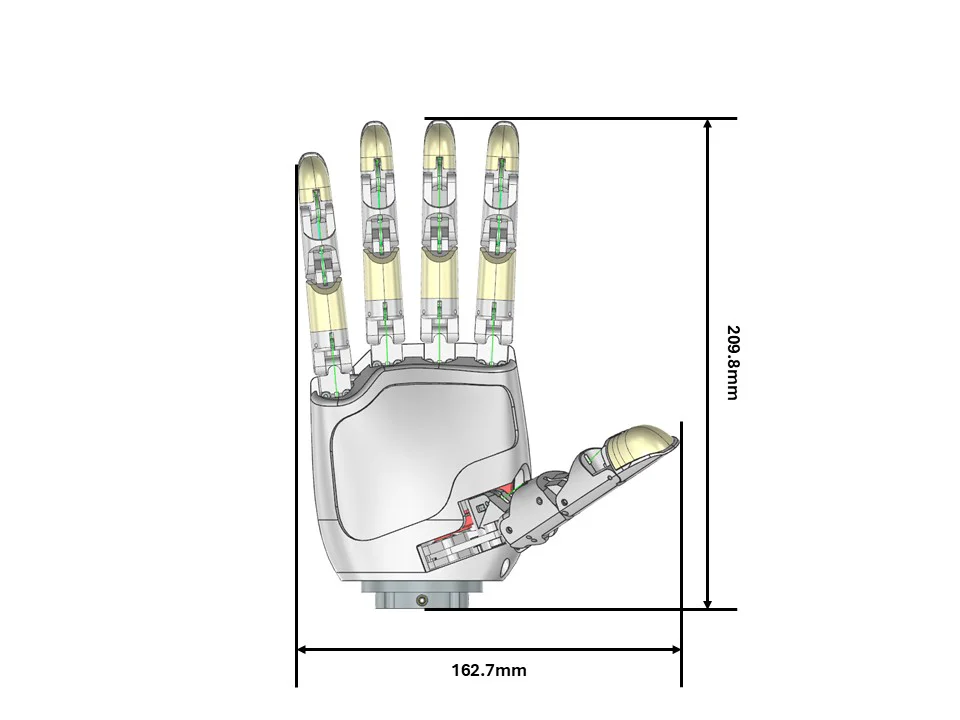
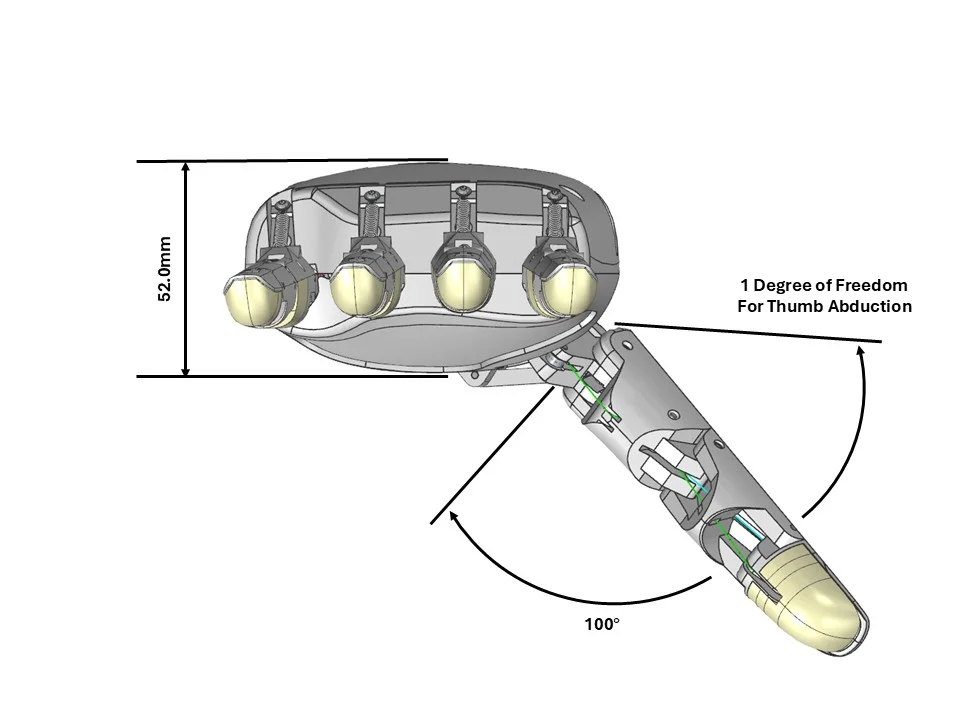
Aero Hand Open is an open-source, tendon-driven robotic hand designed by TetherIA for dexterous manipulation research. Unlike expensive proprietary solutions, this hand focuses on simplicity, reliability, and accessibility — fully 3D-printed structure with off-the-shelf electronic components.
Key Specs: 7 DoF | 16 joints | 5 fingers | 389g | ESP32-S3 controller | 7× Feetech HLS3606M servos
Attribution: TetherIA Inc. — https://github.com/TetherIA/aero-hand-open
License: Design files (CAD/STL/BOM/docs) — CC BY-NC-SA 4.0 | Software (firmware/SDK) — Apache-2.0
Source: https://github.com/TetherIA/aero-hand-open
Docs: https://docs.tetheria.ai | Shop: https://shop.tetheria.ai
Printing
This is a single left hand (all parts are left_ prefixed; the upstream repo also publishes a mirrored right hand under right_ prefixes if you need the opposite hand).
Structural / palm (1 each):
- left_base_link — palm/chassis
- left_t_link — thumb carpometacarpal mount
Five finger chains. Each of the four fingers (index, middle, ring, pinky) is a four-link chain; the thumb is its own four-link chain:
- Index: left_index_proximal / _middle / _distal / _tip
- Middle: left_middle_proximal / _middle / _distal / _tip
- Ring: left_ring_proximal / _middle / _distal / _tip
- Pinky: left_pinky_proximal / _middle / _distal / _tip
- Thumb: left_thumb_mcp / _proximal / _distal / _tip
Mount adapters (pick the one that matches your wrist/base — optional):
- 135degrees_adapter — for a 135° angled mount
- threaded_mount_adapter — for a threaded base mount
Print in PLA, 0.2 mm layer height, tree supports on the build plate only. Per the BOM, several small hardware items are not separate STLs: the 6× cable spools and the silicone finger pads are produced by other means (spools are integral / cast pads use Ecoflex 00-30 in a mold). Buy undersized 2x10 pins — standard 2x10 pins are too tight for the 2x5x2.5 mm bearings and cause joint stiffness. Route the tendons before final assembly of each finger module; retrofitting cables through assembled joints is extremely difficult.
The full set is 24 STL files (22 hand parts + 2 optional mount adapters), driven by 7× Feetech HLS3606M servos.
🖨 印刷ファイル (24)
135degrees_adapter.stl
threaded_mount_adapter.stl
left_base_link.STL
left_t_link.STL
left_thumb_mcp_link.STL
left_thumb_proximal_link.STL
left_thumb_distal_link.STL
left_thumb_tip_link.STL
left_index_proximal_link.STL
left_index_middle_link.STL
left_index_distal_link.STL
left_index_tip_link.STL
必要なハードウェア
| # | Item | Category | Material | Qty | Unit Cost | Total |
|---|---|---|---|---|---|---|
| 1 | Finger Base | 3D Printed | PLA | 4 | 0.02 | 0.10 |
| 2 | Finger MCP | 3D Printed | PLA | 4 | 0.02 | 0.06 |
| 3 | Finger Proximal | 3D Printed | PLA | 4 | 0.14 | 0.58 |
| 4 | Finger Medial | 3D Printed | PLA | 4 | 0.07 | 0.26 |
| 5 | Finger Distal | 3D Printed | PLA | 4 | 0.04 | 0.15 |
| 6 | Cable Spool | 3D Printed | PLA | 6 | 0.02 | 0.11 |
| 7-18 | Thumb parts (6 parts) | 3D Printed | PLA | various | — | — |
| 19 | Finger Distal Pad | Casting | 00-30 Silicone | 4 | 0.03 | 0.11 |
| 23 | Return Spring (PIP) | Purchased | Music Wire | 5 | .27 | 6.35 |
| 24 | Return Spring (MCP) | Purchased | Music Wire | 4 | .27 | 3.08 |
| 25 | Return Spring (CMC) | Purchased | Music Wire | 1 | .93 | .93 |
| 26 | Finger Pull Cable (Kevlar) | Purchased | Kevlar/Vectran | 3 | .29 | .29 |
| 32 | 2x5x2.5mm Bearing | Purchased | Steel | 23 | 0.52 | 1.997 |
| 33 | 1x10 Pin | Purchased | Steel | 16 | 0.158 | .53 |
| 37 | UNDERSIZED 2x10 Pin | Purchased | Steel | 19 | 0.156 | .96 |
| 40 | M2x6 Flanged Torx Screw | Purchased | Steel | 25 | 0.403 | 0.08 |
| 41 | M2x10 Countersunk Torx Screw | Purchased | Steel | 12 | 0.30 | .60 |
| 42 | M3x10 Rounded Torx Screw | Purchased | Steel | 9 | 0.118 | .06 |
似たロボットを探す