


AcroMonk Brachiating Robot
 B
✓ Links verified Aug 31, 2026
Sign up to InstallAbout this program
54 stars on GitHub.
AcroMonk is a minimalist underactuated brachiating robot — it swings hand-over-hand across a horizontal ladder bar using just one quasi-direct drive (QDD) actuator and passive grippers. Published in IEEE Robotics and Automation Letters 2023 (featured in IEEE Spectrum Video Friday), it is the first brachiator with unactuated grippers that can perform more than two consecutive brachiation maneuvers.
Source: https://github.com/dfki-ric-underactuated-lab/acromonk
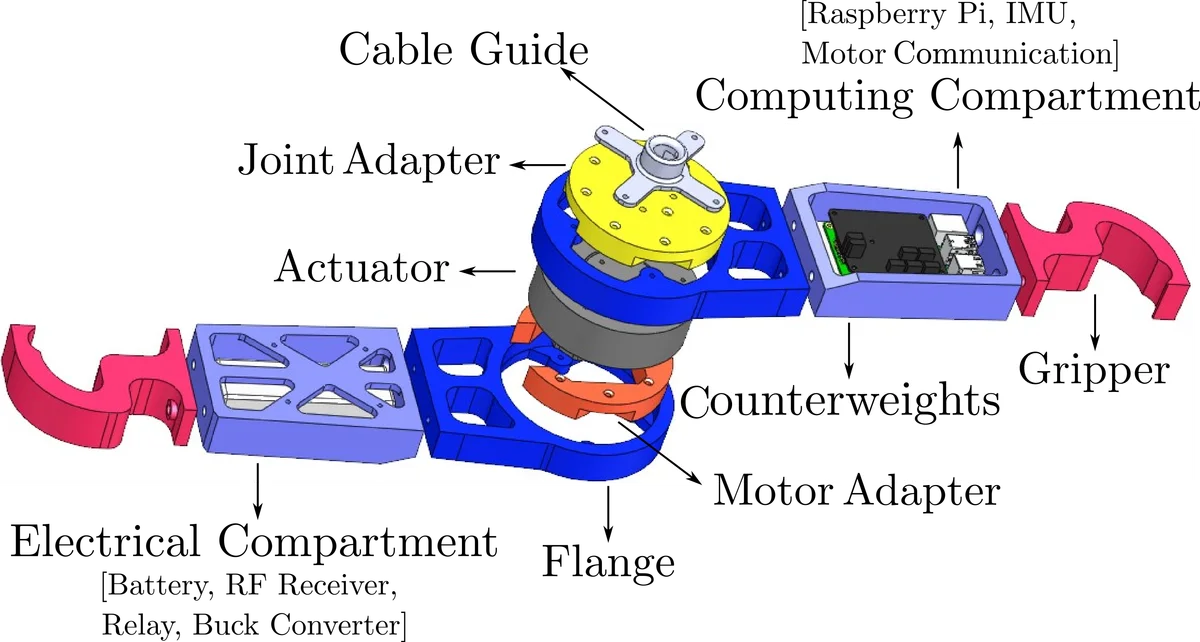
The robot is built from a single brushless QDD motor (MIT Cheetah-style), 3D-printed structural links, and simple passive hook grippers that rely on gravity and swing momentum for release and re-grasp. The absence of gripper actuators dramatically simplifies the mechanical design while making the control problem much harder — AcroMonk must time its swing precisely.
Control methods include trajectory stabilization via TVLQR (time-varying LQR) and reinforcement learning. A full simulation environment (MuJoCo/PyBullet) is provided alongside hardware controllers. The kit is designed to be an affordable research testbed for underactuated locomotion research.
Hardware: 1× quasi-direct drive brushless actuator (MIT Cheetah motor or equivalent), 3D-printed links and gripper hooks, horizontal ladder test bar. Open source under BSD-3-Clause license with accompanying IEEE RA-L paper.
Build Guide
Hardware build files, BOM, and assembly docs: github.com/dfki-ric-underactuated-lab/acromonk/tree/main/hardware
🖨 Print Files (11)
hook_2.STL
hook_2_upper.STL
hook_2_upper_lower.STL
stick_2.STL
hook_2_upper_tip.STL
stick_1.STL
IMU.STL
hook_2_lower.STL
Base.STL
hook_1.STL
link_2.STL
Required Hardware
| Item | Qty | Unit Cost (USD) | Total (USD) | Notes |
|---|---|---|---|---|
| mjbots qdd100 beta 3 quasi-direct-drive servo | 1 | $539 | $539 | Single actuator, the heart of the brachiator — mjbots shop |
| mjbots pi3hat (Raspberry Pi → CAN-FD bridge) | 1 | $149 | $149 | Bridges Pi to qdd100 — mjbots shop |
| Raspberry Pi 4 Model B (4 GB) | 1 | $90 | $90 | Realtime control host — Amazon search |
| MicroSD card 64 GB (A1, U3) | 1 | $14 | $14 | Boot media — Amazon search |
| 6S 1300 mAh LiPo battery (22.2V) — 75C | 1 | $35 | $35 | High-discharge for QDD — Amazon search |
| 24V DC relay (PCB-mount) | 1 | $7 | $7 | Power-arming — Amazon search |
| 30A electronic kill switch (battery cut-off) | 1 | $30 | $30 | Safety — Amazon search |
| Step-down DC-DC voltage regulator (24V → 5V, ≥3A) | 1 | $8 | $8 | Powers the Pi — Amazon search |
| Reely joystick / wired RC controller | 1 | $80 | $80 | Manual swing trigger — Amazon search |
| BASF Ultrafuse PLA filament (1 kg) | 1 | $30 | $30 | Body parts — Amazon search |
| M3 / M4 socket-head screw + nut assortment (stainless) | 1 | $15 | $15 | Frame fasteners — Amazon search |
| Resistor + varistor + JST cabling kit | 1 | $12 | $12 | Misc passives & wiring — Amazon search |
| 14 AWG silicone hookup wire (red/black, 10 ft each) | 1 | $15 | $15 | Battery → relay → qdd100 — Amazon search |
| XT60 connector pair | 2 | $2 | $4 | Battery connector — Amazon search |
| Aluminum 20×20 V-slot extrusion + brackets (test bar / "ladder") | 1 | $50 | $50 | The bar the AcroMonk brachiates on — Amazon search |
| Foam crash mat / safety net | 1 | $30 | $30 | LiPo + falls = safety first — Amazon search |
Estimated total: $1,050–$1,200 USD (matches the project's stated €950–1,000 testbench, plus mat/extrusion). Source: https://github.com/dfki-ric-underactuated-lab/acromonk/blob/main/hardware/bills-of-materials.md.
Explore similar robots