Watney Telepresence Rover
 B
このプログラムについて
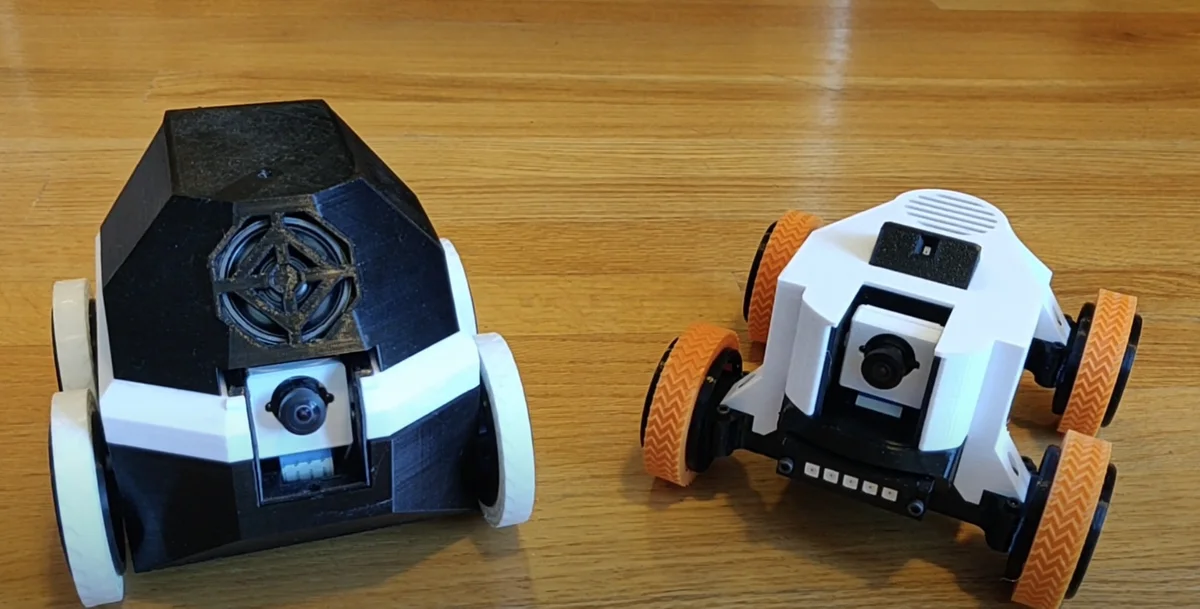
Watney is an open-source, Raspberry Pi-powered telepresence rover built from readily available parts — low-latency HD video, bi-directional audio with echo cancellation, and a self-docking charging cradle. All non-electronic parts are 3D printable.
Source: github.com/nikivanov/watney by nikivanov License: GNU GPL-3.0 — copyleft; any distributed derivative firmware/software must remain GPL-3.0 licensed.
Hardware
- Drive: 2x N20 geared DC motors (differential/tank steering), driven by a DRV8833 driver
- Camera: Raspberry Pi fisheye camera on a tilting SG90 servo mount, streamed over WebRTC (Janus + GStreamer) with hardware H264 encode
- Audio: I2S mic + MAX98357 amp/speaker with echo cancellation and TTS
- Lighting: APA102/SK9822 addressable LED strip (headlights)
- Power: 2x 18650 Li-ion cells behind a GeeekPi UPS Plus V5, with a magnetic pogo-pin charging dock
- Brain: Raspberry Pi 3A+ (community reports of Pi 4B working; Pi Zero 2 unconfirmed)
What this program provides
A browser-based learning interface — joystick drive, camera tilt, and a stop button — mapped to the real motor/servo layout described in the source repo. Full telepresence functionality (WebRTC video/audio, LEDs, TTS, self-docking) lives in the original Raspberry Pi firmware; build and flash it from the source repo (Releases tab has a ready SD card image) to get the complete experience. This orobot program is a starting point for understanding and extending the control logic, not a replacement for the original firmware image.
⚠️ Safety: the build uses Lithium-Ion 18650 cells — handle carefully, don't puncture or short them.
⚠️ No built-in auth: the original Watney interface has no authentication; the maintainer recommends Zerotier for secure remote access.
🖨 印刷ファイル (24)
Base.stl
Camera bucket.stl
Power Button.stl
camera gear.stl
contact board.stl
headlight case.stl
headlight mount.stl
mic body.stl
mic holder.stl
motor holder.stl
servo gear mg90s.stl
servo gear.stl
必要なハードウェア
| Part | Price | Notes |
|---|---|---|
| Raspberry Pi 3A+ | $25 | Designed for 3A+; Pi 4B reported to work (unconfirmed by maintainer), Pi Zero 2 unconfirmed |
| Micro SD Card 8GB+ | $5 | |
| 2A USB charger | $5 | |
| 4x N20 geared motors, 10mm shaft, 200 rpm, 6V | $14 total | Lower RPM trades speed for torque |
| GeeekPi UPS Plus V5 EP-0136 | $30 | Update UPS firmware to v10 before assembly (older firmware locks up) |
| 2x 18650 batteries | $20 | Price is for 2 Samsung 25R cells |
| MAX98357 I2S amplifier | $4 | |
| 100k Ohm resistor | $3 | Optional, sold in packs of 100 |
| 40mm full range speaker | $5 | Usually sold in packs of 2 |
| Sipeed I2S microphone MSM261S4030H0 | $4 | |
| SG90 servo | $4 | MG90 metal-gear version should be a drop-in replacement (untested by maintainer) |
| Raspberry Pi fisheye camera module | $10 | See camera compatibility tip re: Camera Module v3 |
| DRV8833 motor driver | $2 | |
| 2.54mm 4-pin screw terminal | $3 | |
| SK9822 or APA102 144 LED/m strip (non-waterproof/IP30) | $20 | Only 5 LEDs needed; shortest available strip is 1m |
| 4x Keystone 209 contacts | $6 | Charging dock contacts |
| Micro USB female breakout board | $2 | |
| 2x USB Type-A male breakout board | $2 |
似たロボットを探す