Maker's Pet Loki
 B
このプログラムについて
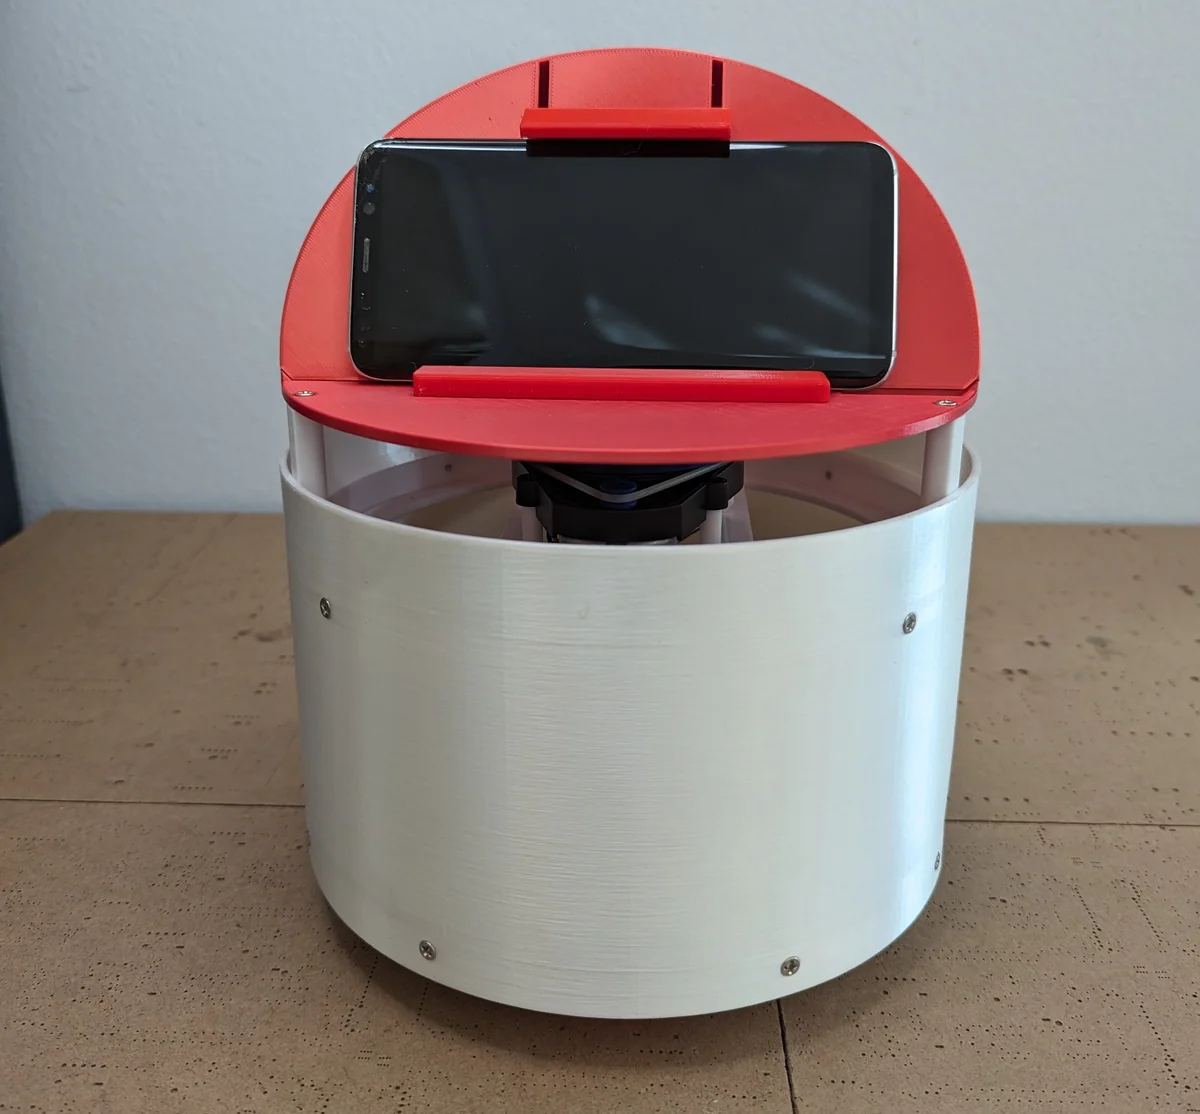
Maker's Pet Loki is an open-source, 3D-printed home pet robot built on the Kaia.ai ROS2 robotics platform. It's a 200mm round differential-drive base sized to fit common 210x250mm and 220x220mm print beds, topped with a spinning laser distance sensor for room mapping and a phone/tablet mount that doubles as its "face."
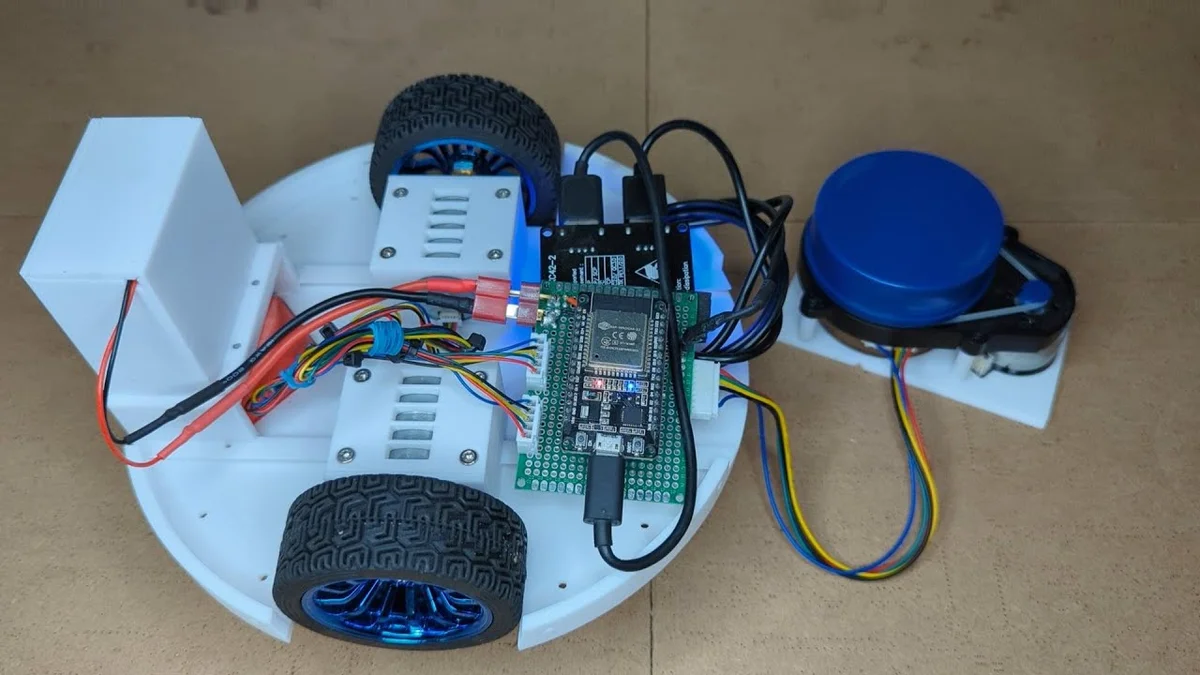
Loki uses two BLDC gearmotors for locomotion, a spinning LiDAR (YDLIDAR X4/X3/X2, Neato XV11, LDS02RR, or RPLIDAR A1 are all supported) for 360-degree room scanning, and an ESP32 microcontroller running Kaia.ai's Arduino/micro-ROS firmware to bridge sensors and motors to a ROS2 stack. Once paired with the Kaia.ai software (ROS2 Humble/Iron via Docker), Loki can autonomously map a room (Cartographer SLAM), navigate with Nav2, explore unknown spaces, and be driven manually via keyboard teleop.
What you get in this Program:
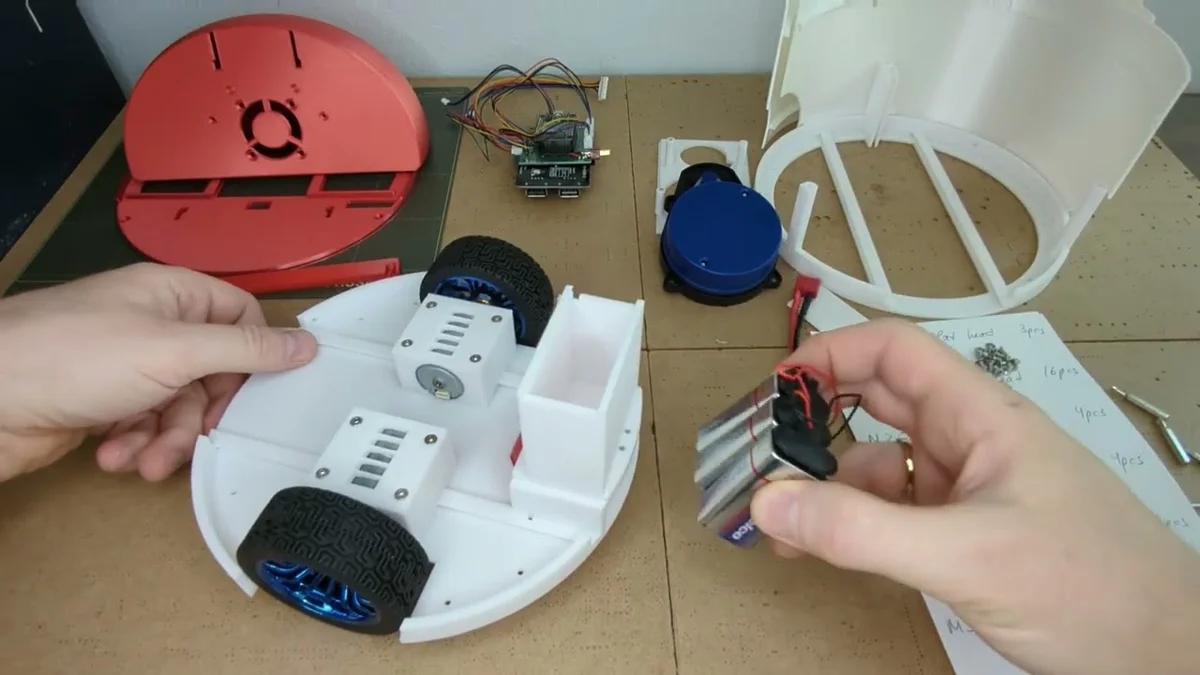
- The 3D-printable STL parts for the round chassis, head, bumpers, battery pack, and sensor mounting plates (choose the plate matching your LiDAR model)
- A learning-mode control stub (drive + stop) that runs in the orobot IDE, so you can explore the Program Editor pattern before wiring up the real Kaia.ai ROS2 stack
- The real build: 3D print the parts, assemble per the official videos, flash the kaiaai/firmware Arduino sketch to an ESP32, then bring up ROS2 via the Kaia.ai Docker setup
Attribution: Design, firmware, and ROS2 packages by Ilia O. / Maker's Pet (REMAKE.AI), licensed Apache 2.0. Source: https://github.com/makerspet/makerspet_loki (STL/CAD files live in the companion repo https://github.com/makerspet/3d_models, firmware in https://github.com/kaiaai/firmware).
Hardware note: Loki's real self-driving stack (ROS2, Cartographer SLAM, Nav2) runs on the ESP32 + micro-ROS + a companion PC/laptop over WiFi, not on orobot's own firmware. This Program's device code is a simplified learning stub for the orobot IDE — full autonomous behavior requires following the upstream build/bring-up instructions.
🖨 印刷ファイル (12)
Battery Pack 3x9V Upright Lid.stl
Battery 3x9V Upright Pedestal.stl
Battery Pack 3x9V Upright.stl
Bumper front.stl
Bumper back.stl
Handset Footrest.stl
Handset Clamp.stl
Motor bracket x2.stl
Head.stl
LDS02RR Plate.stl
Caster wheel with break-off pedestal.stl
Middle plate.stl
必要なハードウェア
| Item | Qty | Unit Cost | Notes |
|---|---|---|---|
| ESP32-WROOM-32 module | 1 | ~$5 | Microcontroller |
| ESP32 breakout/driver board | 1 | ~$10 | Motor driver + power distribution |
| 3x 9V battery pack + XT30 cable | 1 | ~$3 | Amazon |
| Laser distance sensor (LDS02RR, YDLIDAR X4/X3/X2, Neato XV11, or RPLIDAR A1) | 1 | ~$15-30 | AliExpress; pick the matching sensor mounting plate STL |
| Sensor adapter board | 1 | ~$5 | Maker's Pet store |
| BLDC gearmotor (CHR-GM25 or similar, ~0.5-1.5 Kg*cm torque) | 2 | ~$11 each | AliExpress |
| 65mm wheel + shaft adapter | 2 | ~$4 each | Generic online shops |
| 3D print filament (PLA or PETG) | ~0.5 kg | ~$10 | Chassis + head + plates |
Estimated total (excluding your own 3D printer): roughly $66-$100 depending on LiDAR model chosen. Source: Maker's Pet Robot Assembly BOM (dated Feb 2024, prices drift).
似たロボットを探す