


Dexter HD/HDI
 B
✓ リンク確認済み Aug 31, 2026
インストールするには登録してくださいこのプログラムについて
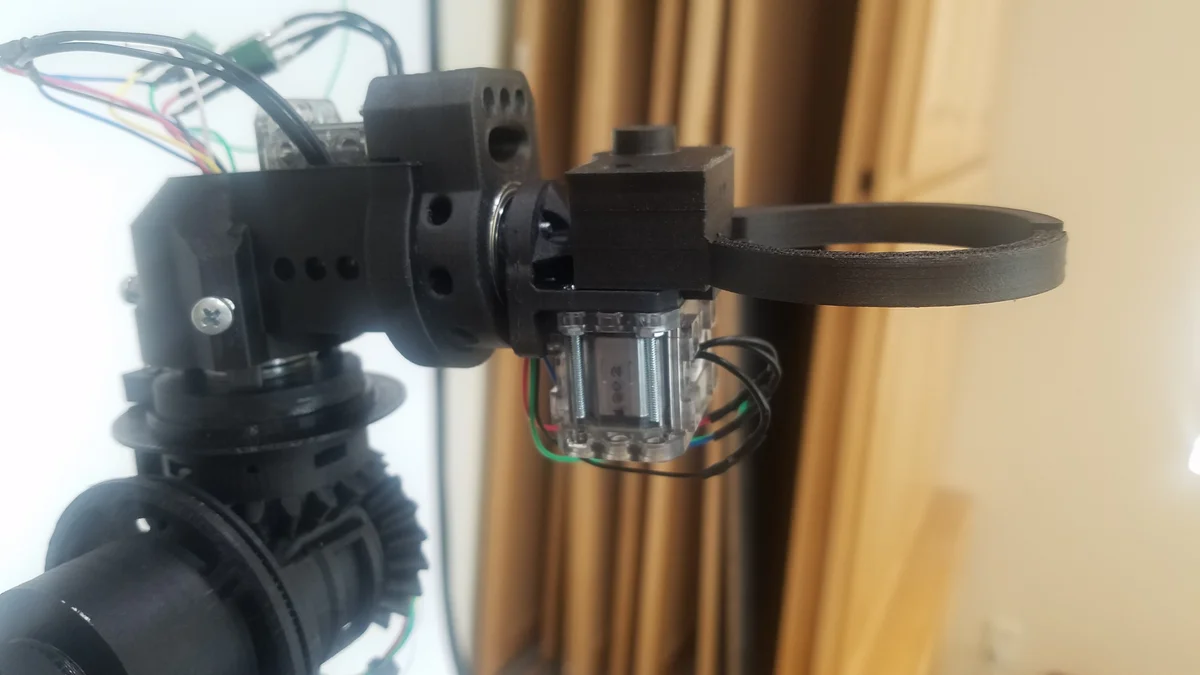
Dexter HD/HDI is an open-source 5+ axis precision robot arm developed by Haddington Dynamics. It uses NEMA-17 stepper motors paired with harmonic drives on the main joints, and custom quadrature optical encoders on every axis for true closed-loop position feedback - a level of precision rarely seen in hobbyist-grade arms. Motion is calculated and served by an onboard MicroZed FPGA/ARM computer running Haddington's custom gateware and DexRun.c firmware, programmed through DDE (Dexter Development Environment), a full JavaScript-based IDE built specifically for this robot.
This orobot.io Program is a learning interface, not a drop-in replacement for Dexter's real control stack. Dexter's actual joint motion, calibration, and job execution run on its own onboard computer - to build and operate a real Dexter, follow the official GitHub Wiki and DDE documentation.
Attribution: Haddington Dynamics (https://github.com/HaddingtonDynamics/Dexter), licensed GPLv3. Project site: http://hdrobotic.com/. Wiki: https://github.com/HaddingtonDynamics/Dexter/wiki
Key resources from the source project:
- STL files: https://www.thingiverse.com/thing:3206154 (with update: https://www.thingiverse.com/thing:3781990)
- Kinematic CAD model (Fusion 360, exportable to STEP/IGES/OBJ/STL/etc.): https://a360.co/3eoAQqo
- Bill of materials (Google Sheet "Common" tab): https://docs.google.com/spreadsheets/d/1tPxJF4zsaoBsXhz2b6sy5hTPxMfhjwwAfAAC_93CtzM/edit
- Assembly photos: https://photos.app.goo.gl/jGmsnxtytvdYhgUi8
- Build notes: https://github.com/HaddingtonDynamics/Dexter/wiki/HD-Build-Notes
- DDE IDE releases: https://github.com/cfry/dde
Note: this repo's STL/CAD assets are hosted externally on Thingiverse and Fusion 360 (OnShape/A360), not committed directly to the GitHub repo, so this Program links to them rather than mirroring local copies.
🖨 印刷ファイル (14)
ArmBody_v1.stl
BaseLite_v1.stl
BaseMountBottom_v1.stl
DiffBodyA_v1.stl
DiffBodyB_v1.stl
DiffGearAxle_v1.stl
DynamicFinger_v1.stl
EndArmHub_v1.stl
ExternalGear_v1.stl
FlexSplineAttach_x3_v1.stl
MainPivot_v1.stl
NewBeltPulley_v1.stl
| Item | Qty | Type | Notes |
|---|---|---|---|
| NEMA-17 Stepper Motor | 5 | Actuator | One per main axis; harmonic drives on 3 of them |
| DYNAMIXEL XL-320 Servo | 1 | Actuator | End-effector twist/grip axis |
| MicroZed FPGA/ARM Board | 1 | Computer | Xilinx Zynq SoC; runs custom Gateware + DexRun.c firmware |
| Motor Control Board | 1 | Electronics | Custom PCB, see Hardware/Motor PCB in repo |
| Optical Encoder Board | 5 | Electronics | One per axis, closed-loop position feedback |
| LED + Phototransistor | 1 set | Electronics | Optical encoder emitter/detector pair |
| Power Supply | 1 | Electronics | Robot power |
| 6810 Bearing | 6 | Hardware | Off-the-shelf |
| 6703 Bearing | 6 | Hardware | Off-the-shelf |
| MR128 Bearing | 7 | Hardware | Off-the-shelf |
| Flex Spline | 3 | Hardware | Harmonic drive component |
| Wave Generator | 3 | Hardware | Harmonic drive component |
| Stator Gear | 3 | Hardware | Harmonic drive component |
| GT2 Belts + Pulleys | assorted | Hardware | Base/wrist drive transmission |
| M2 / M3 Bolts, Nuts, Washers | assorted | Fasteners | Off-the-shelf hardware store items |
| Carbon Fiber Strake (various sizes) | assorted | Structural | Fabricated CF stock, e.g. dragonplate.com |
| 3D-printed structural parts | ~40+ | Printed | See Thingiverse links below |
似たロボットを探す